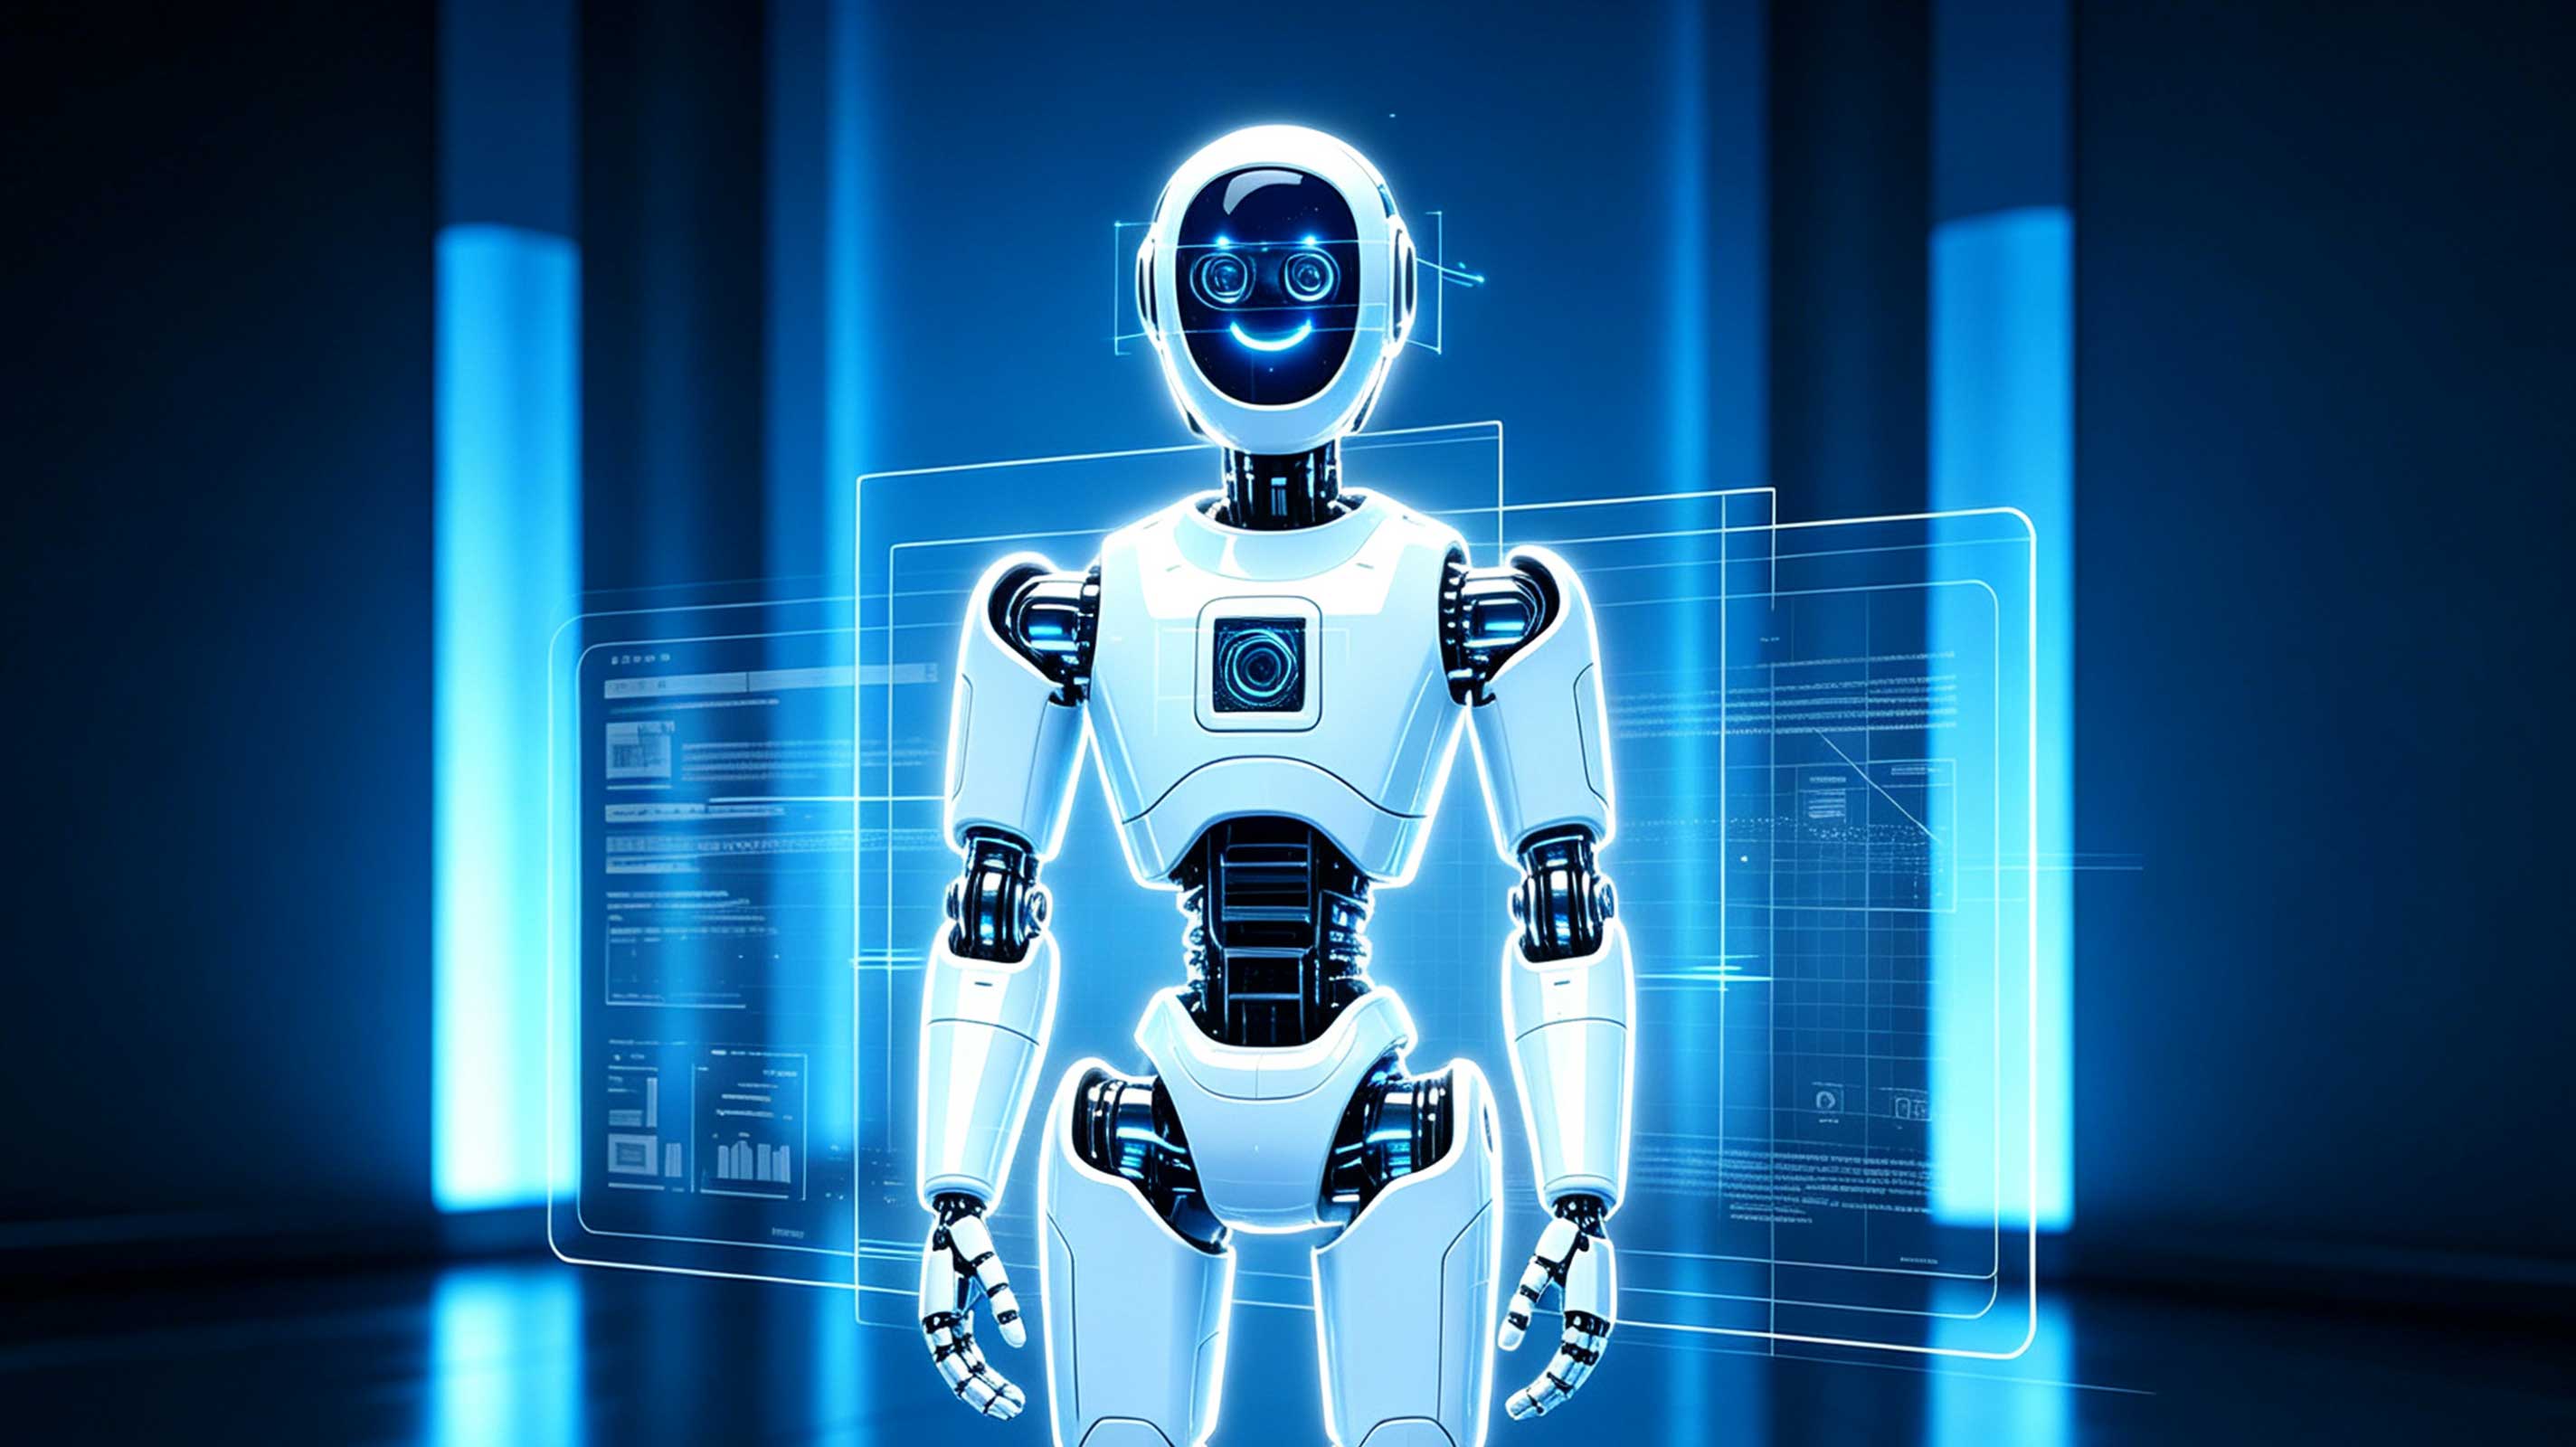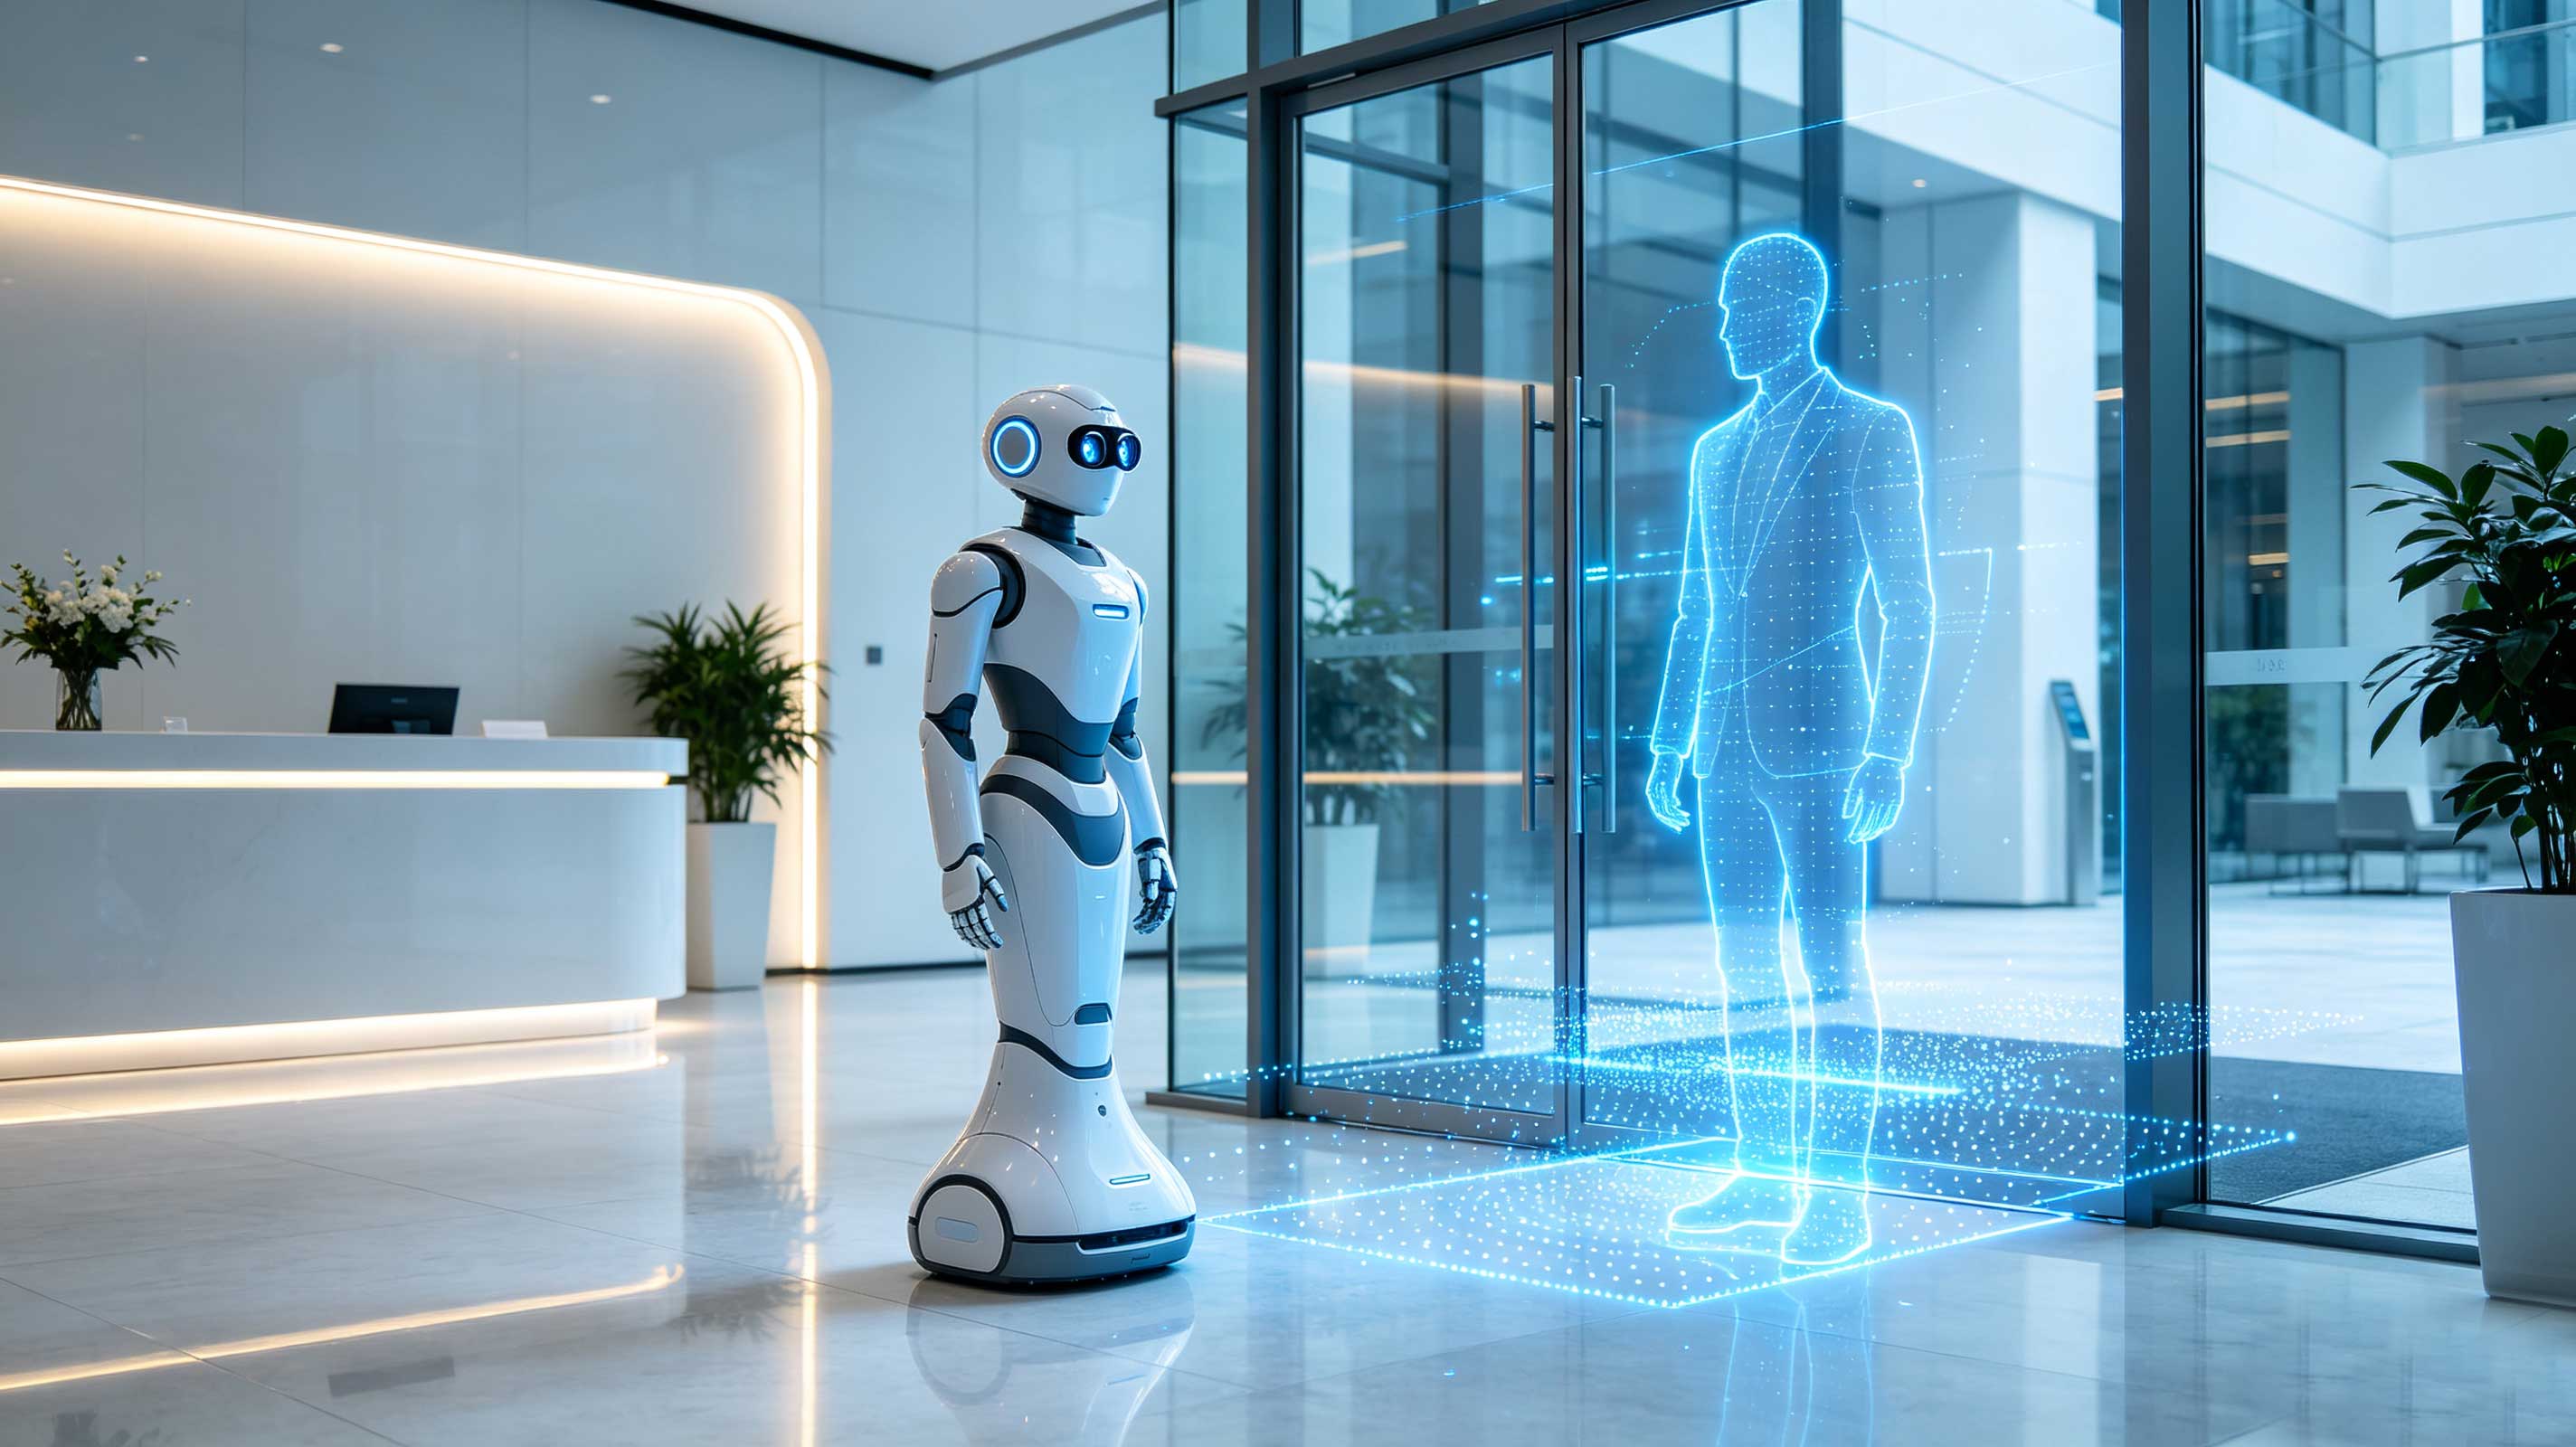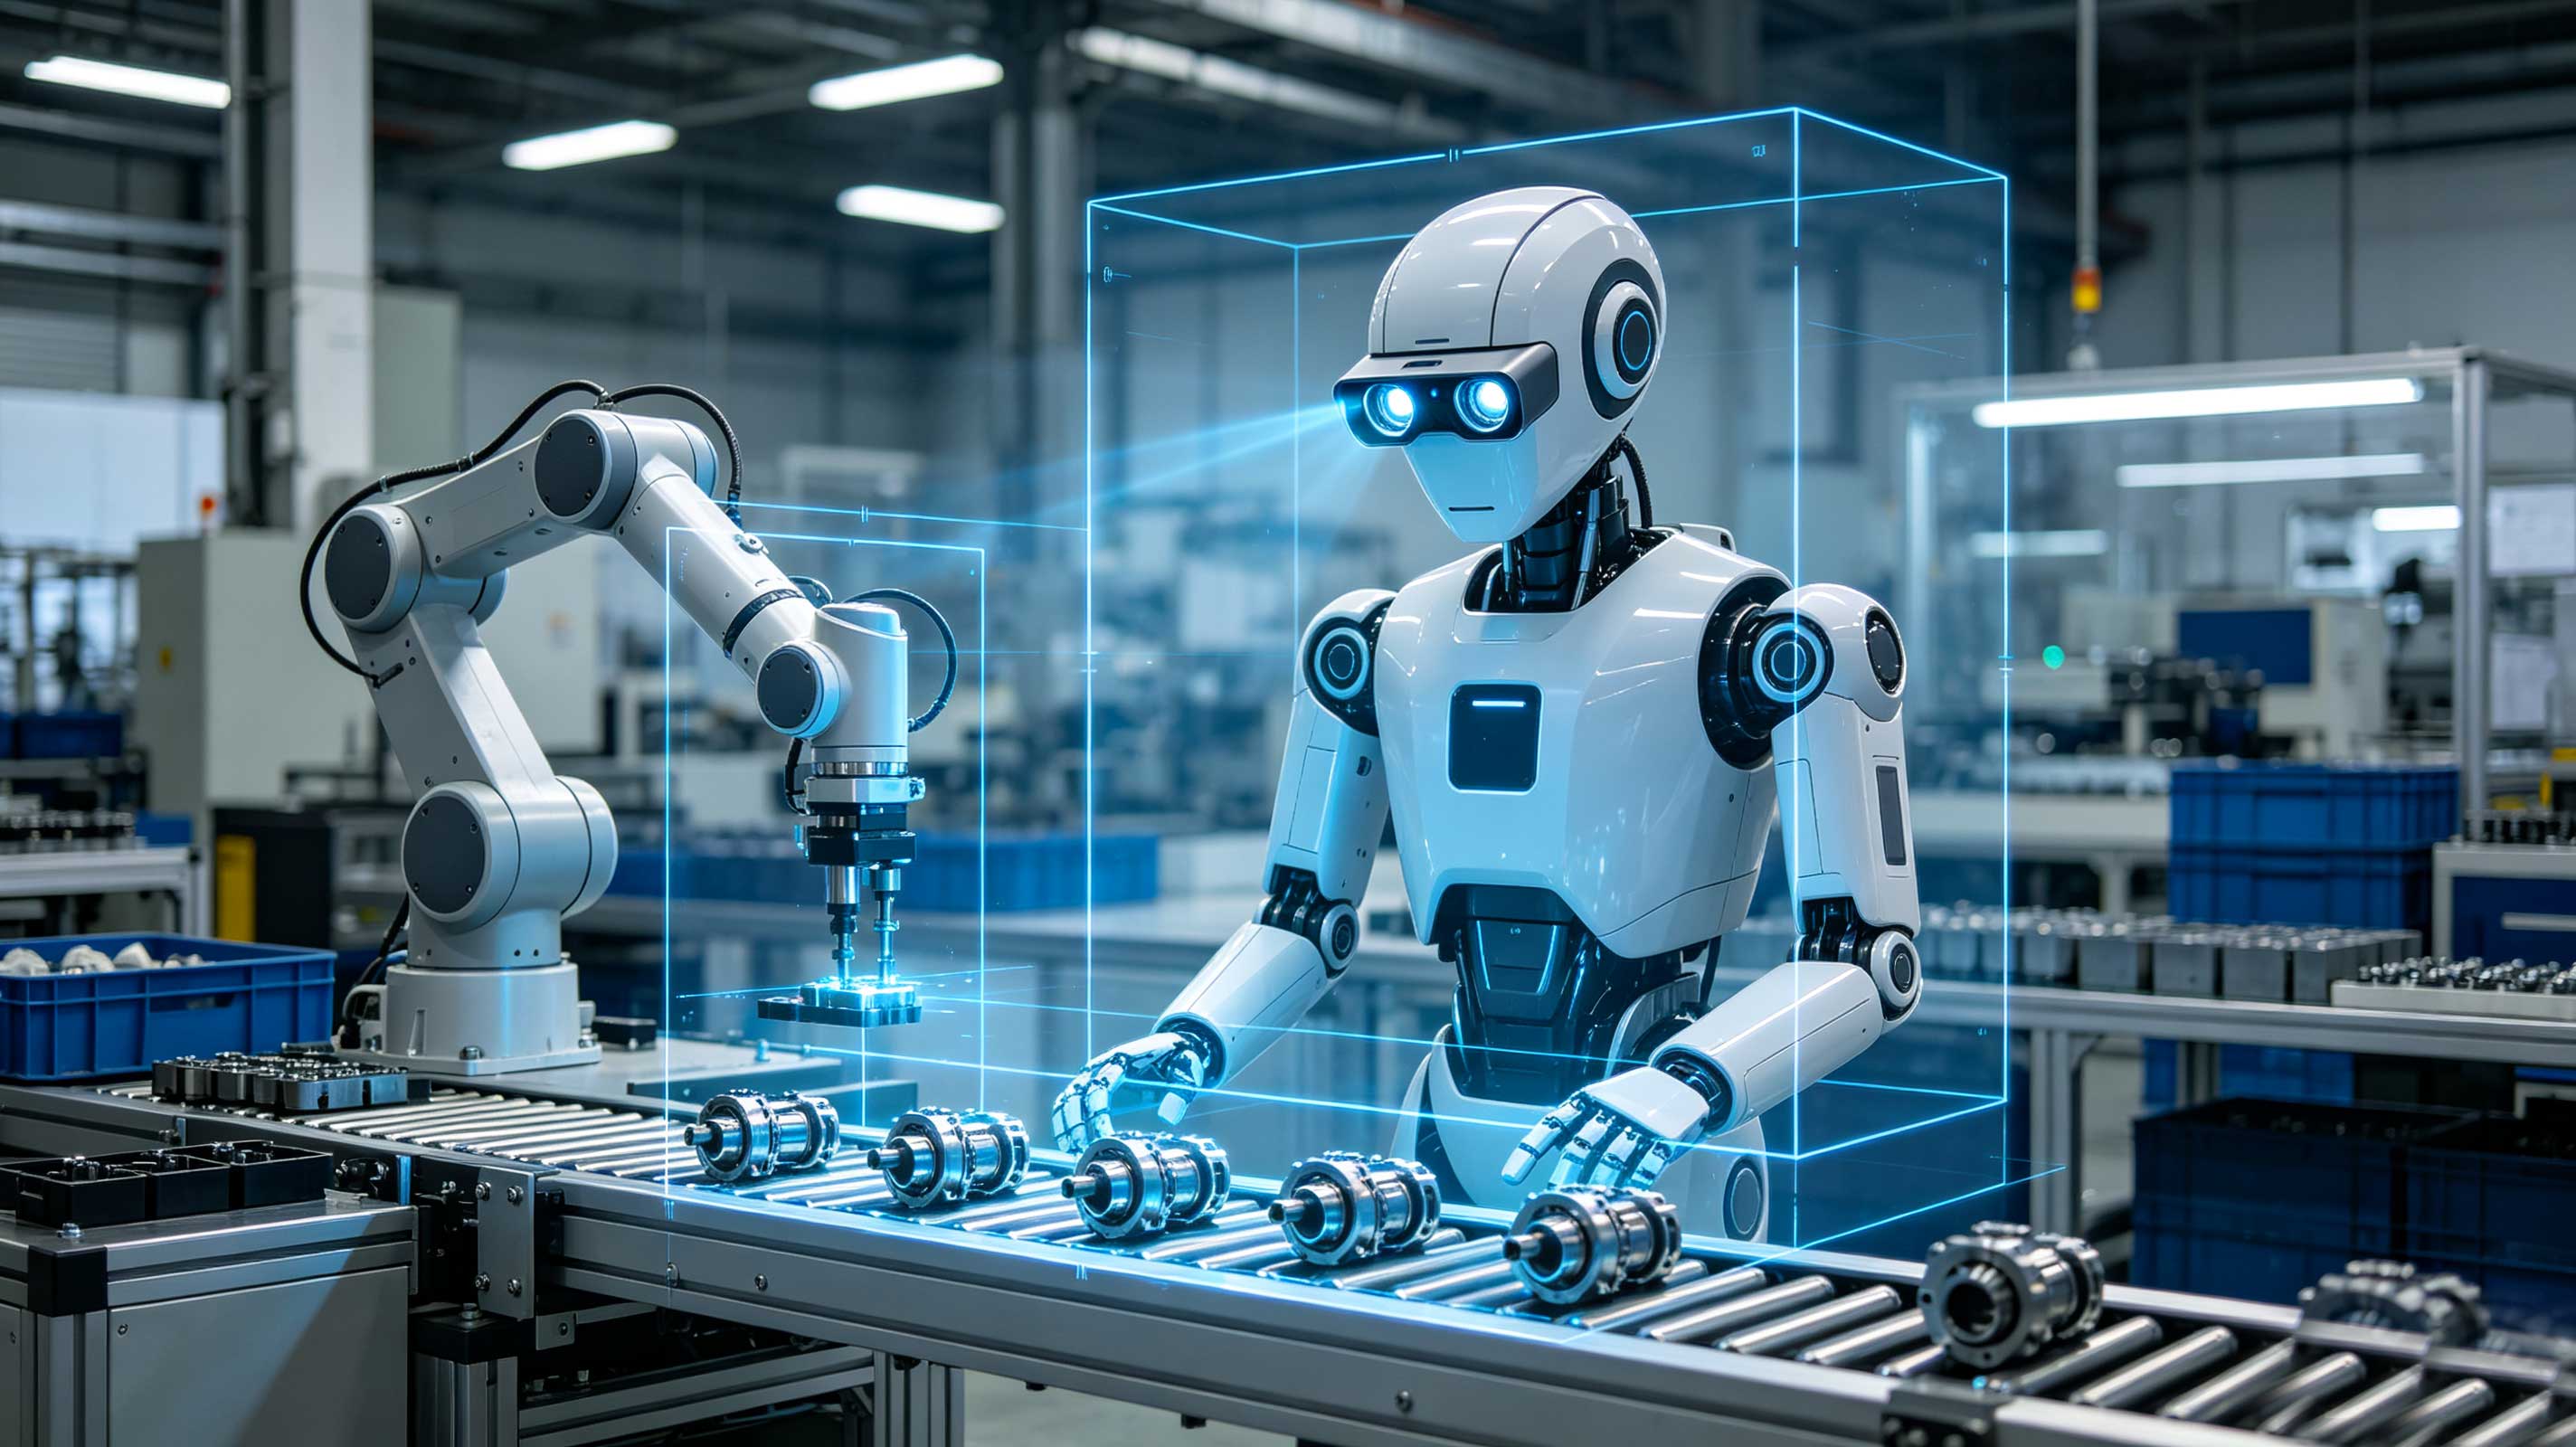
Humanoid Robot
Perceive Surroundings, Navigate Collision-Free.
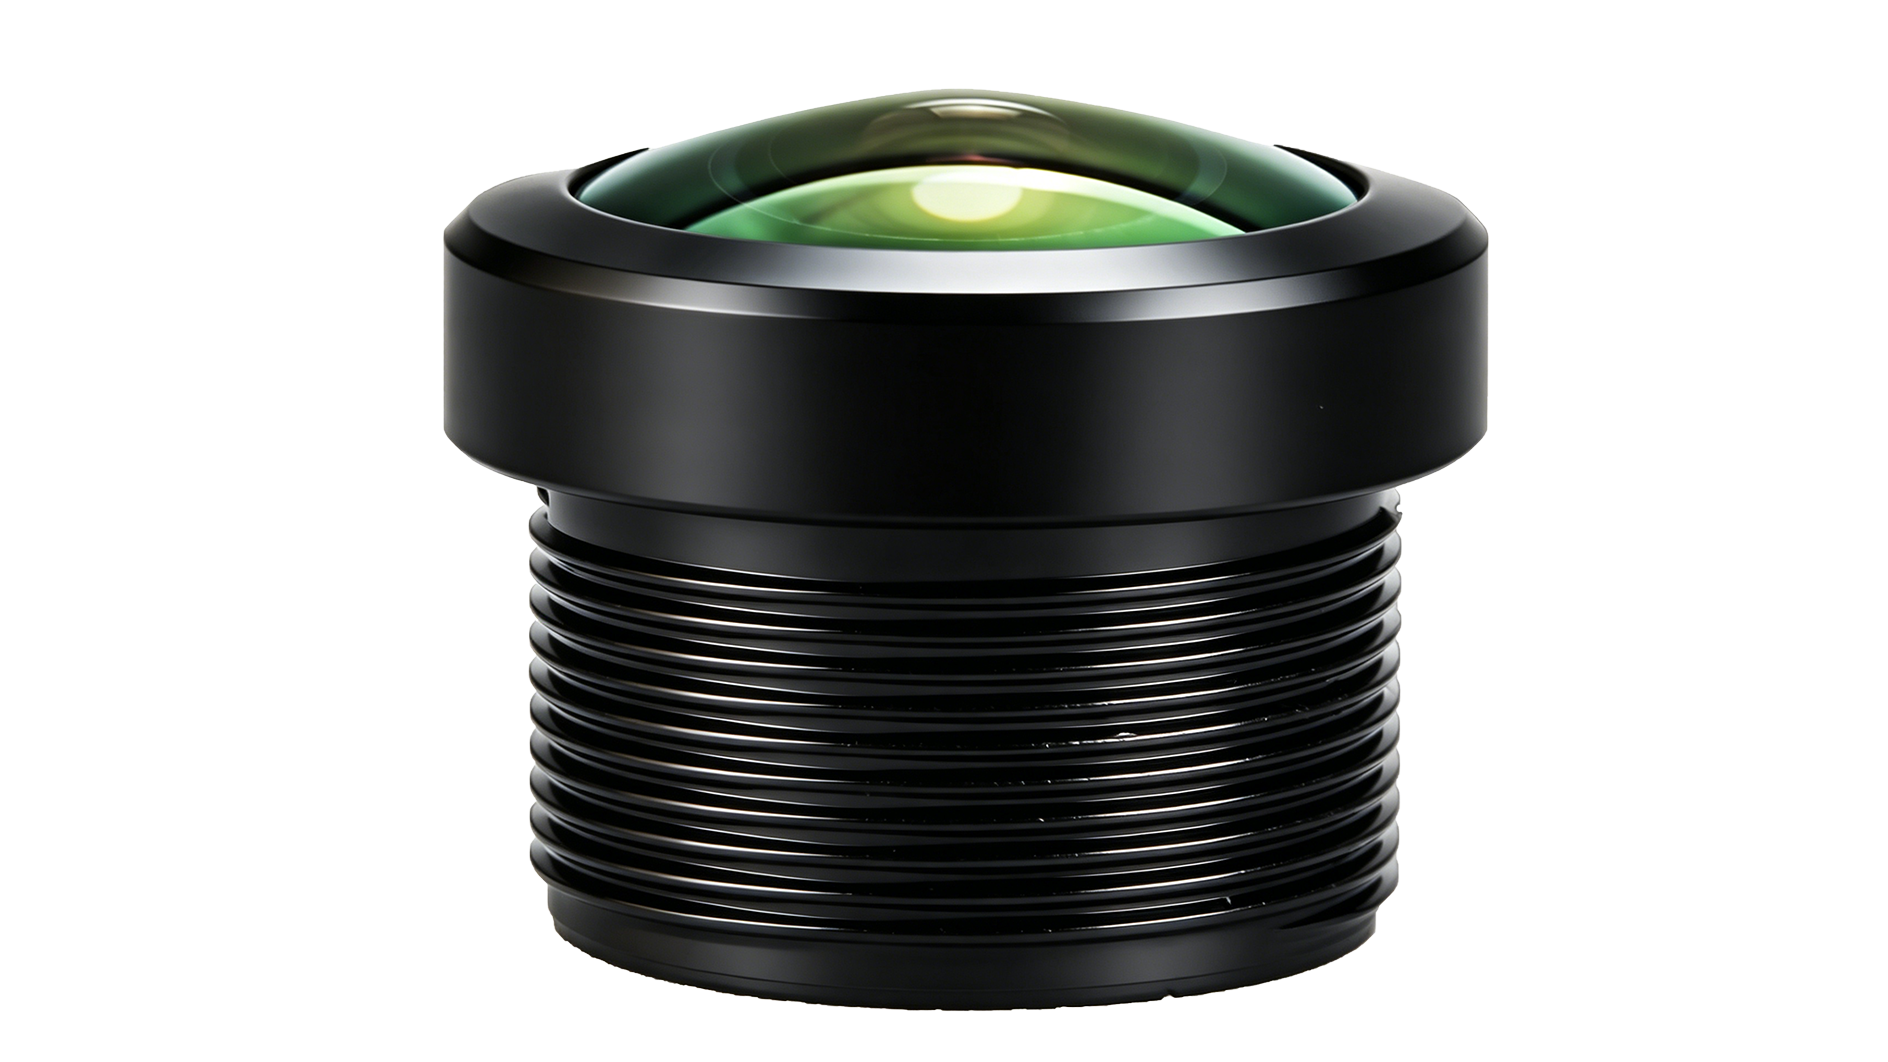
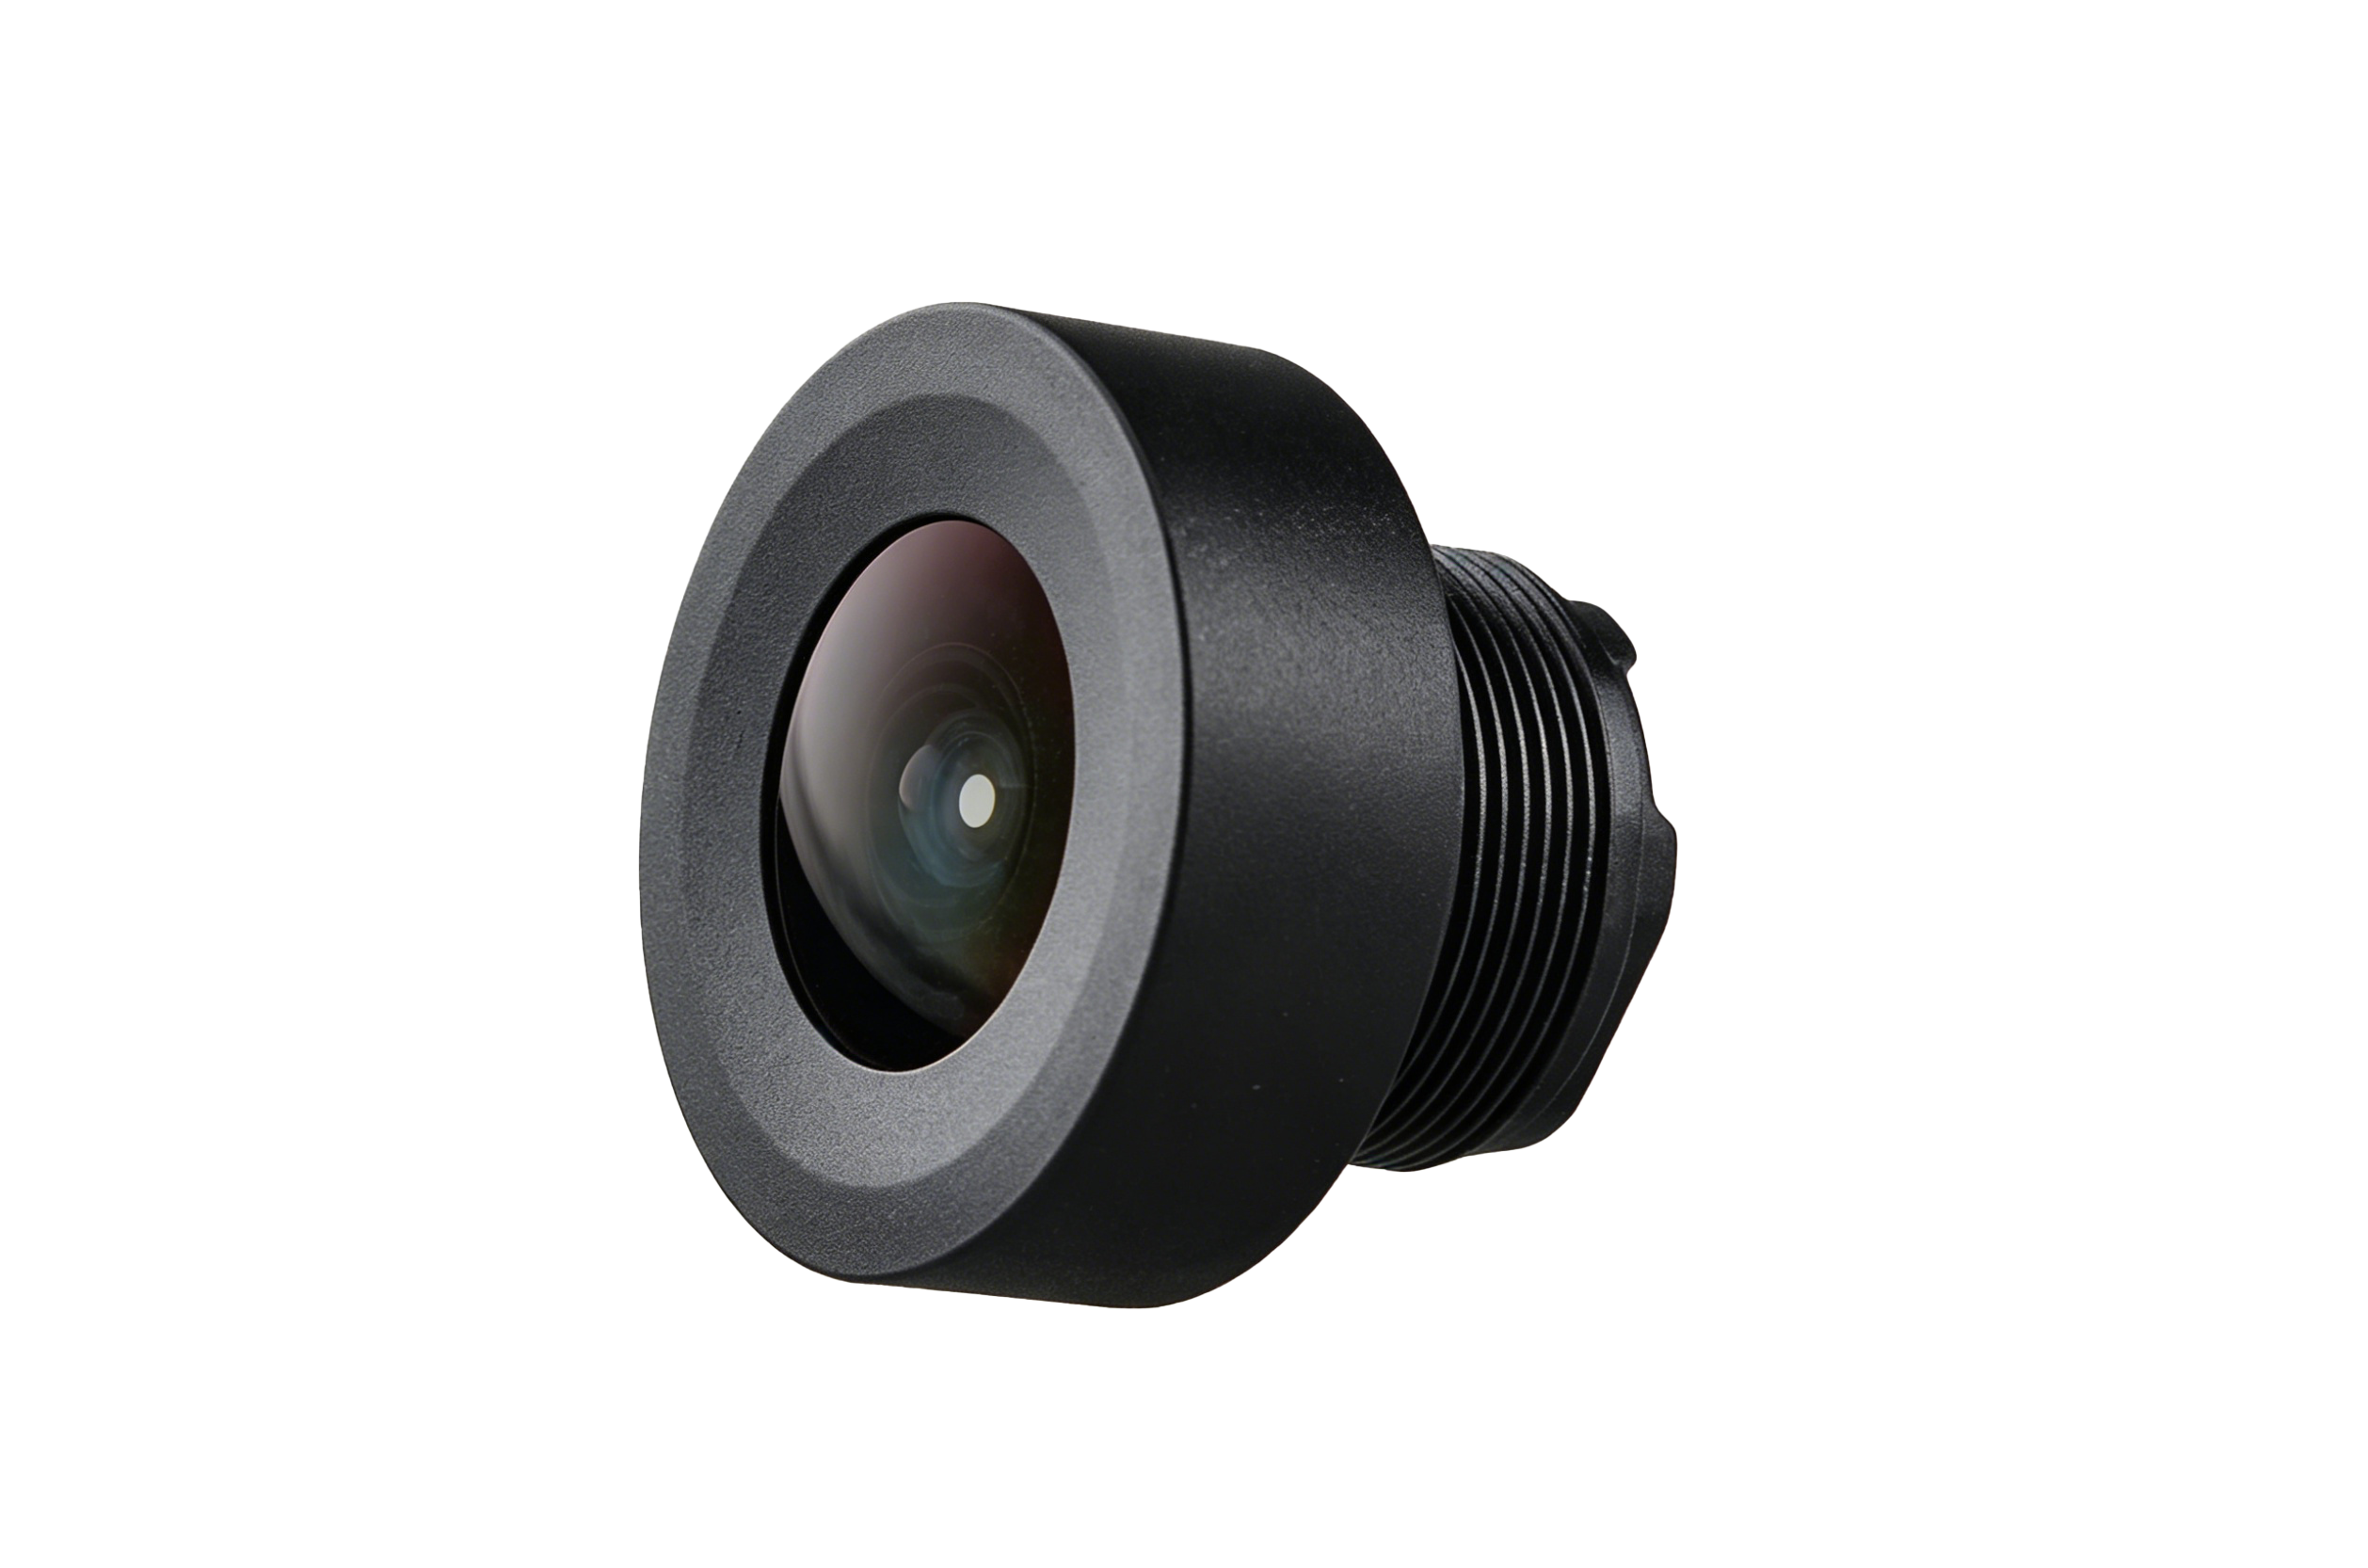
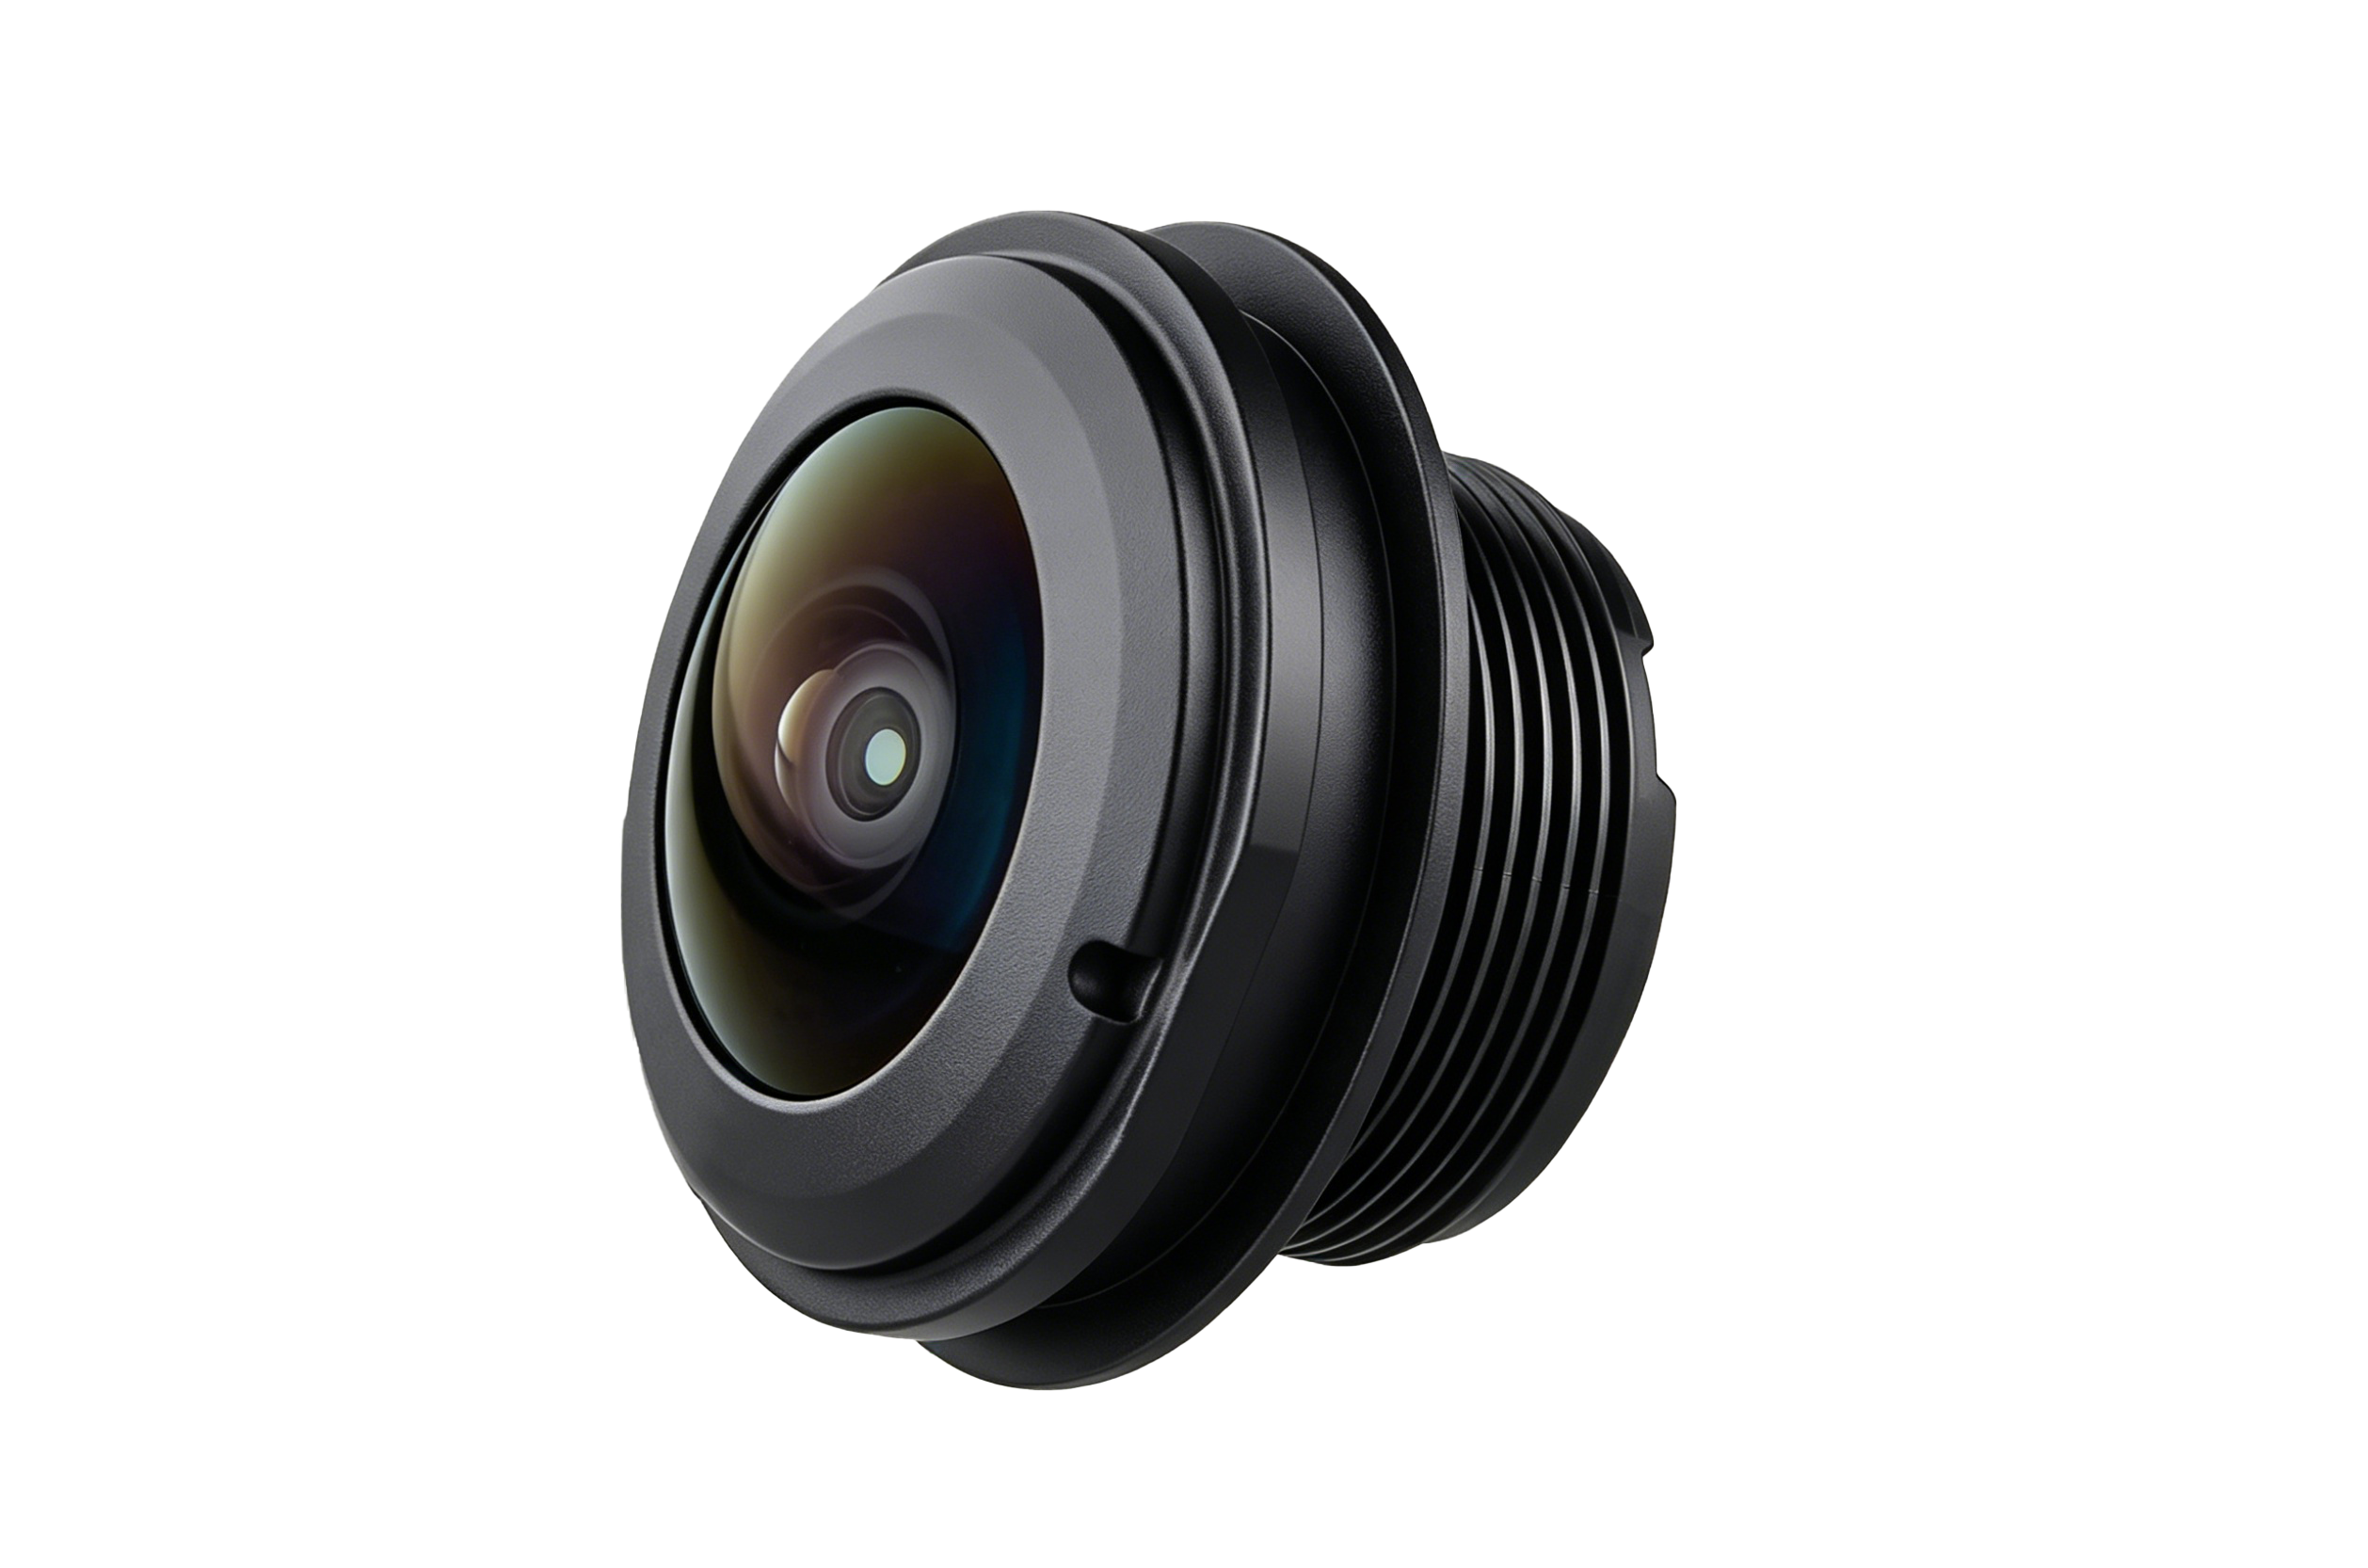
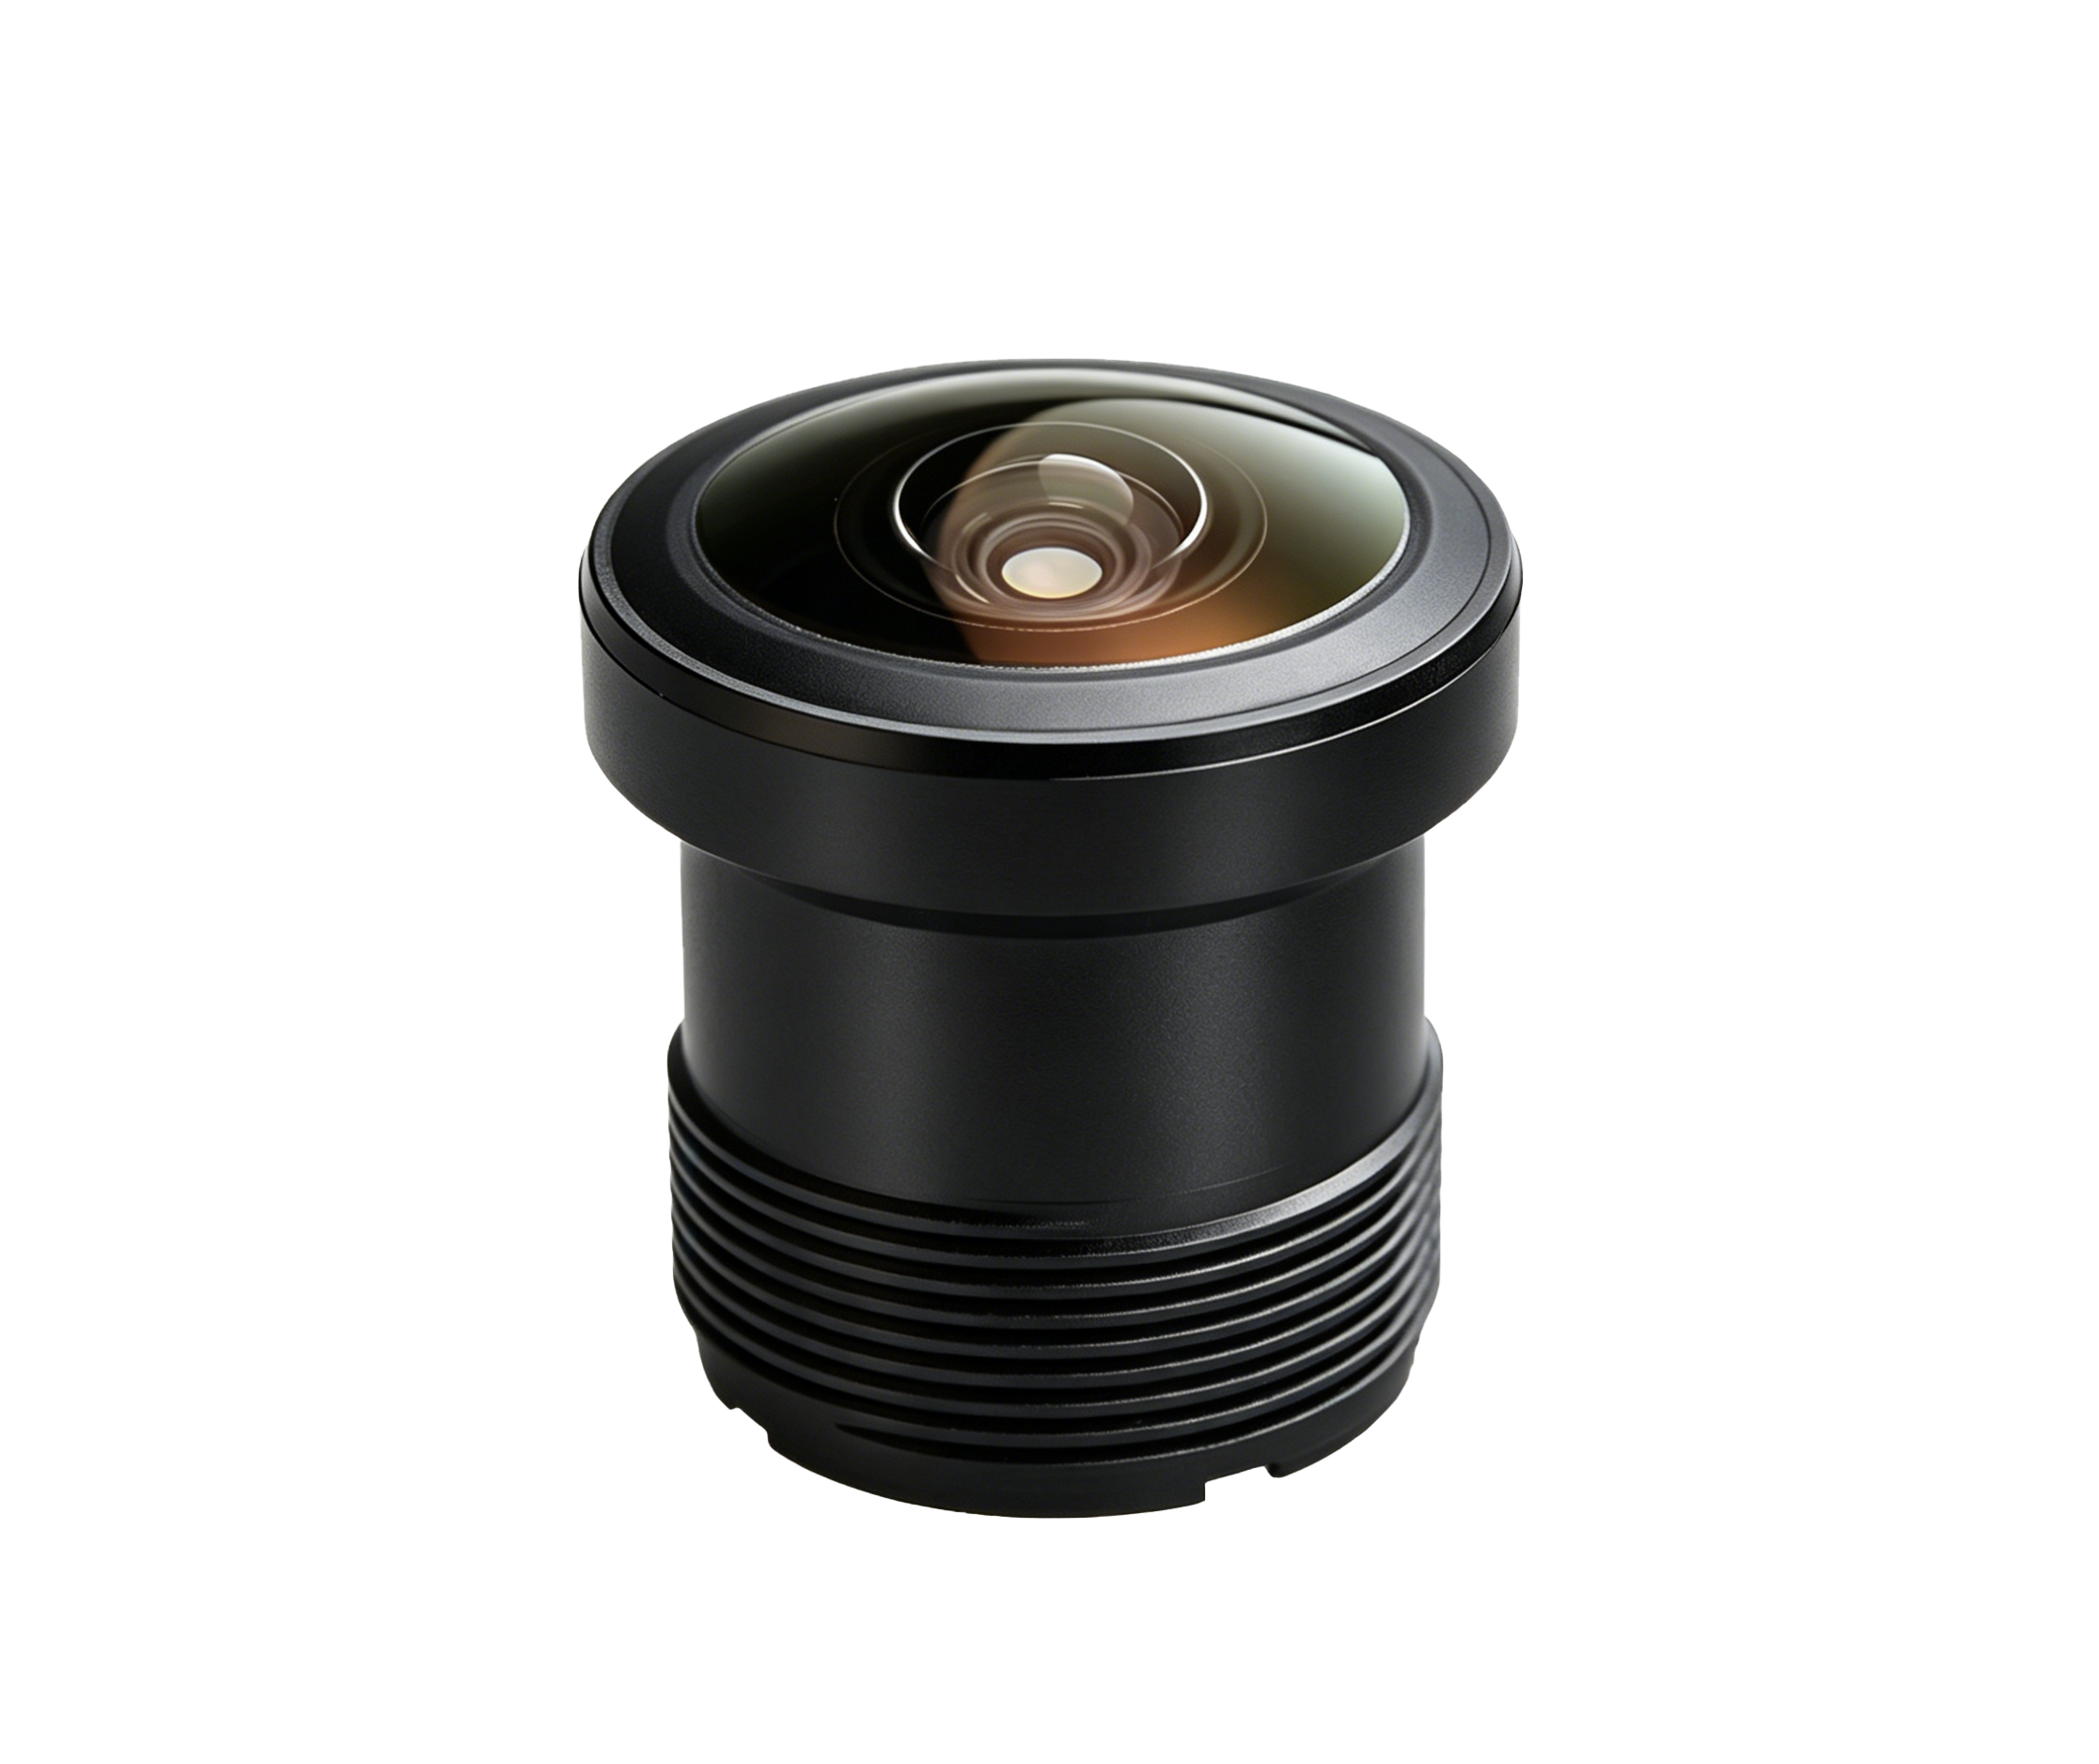
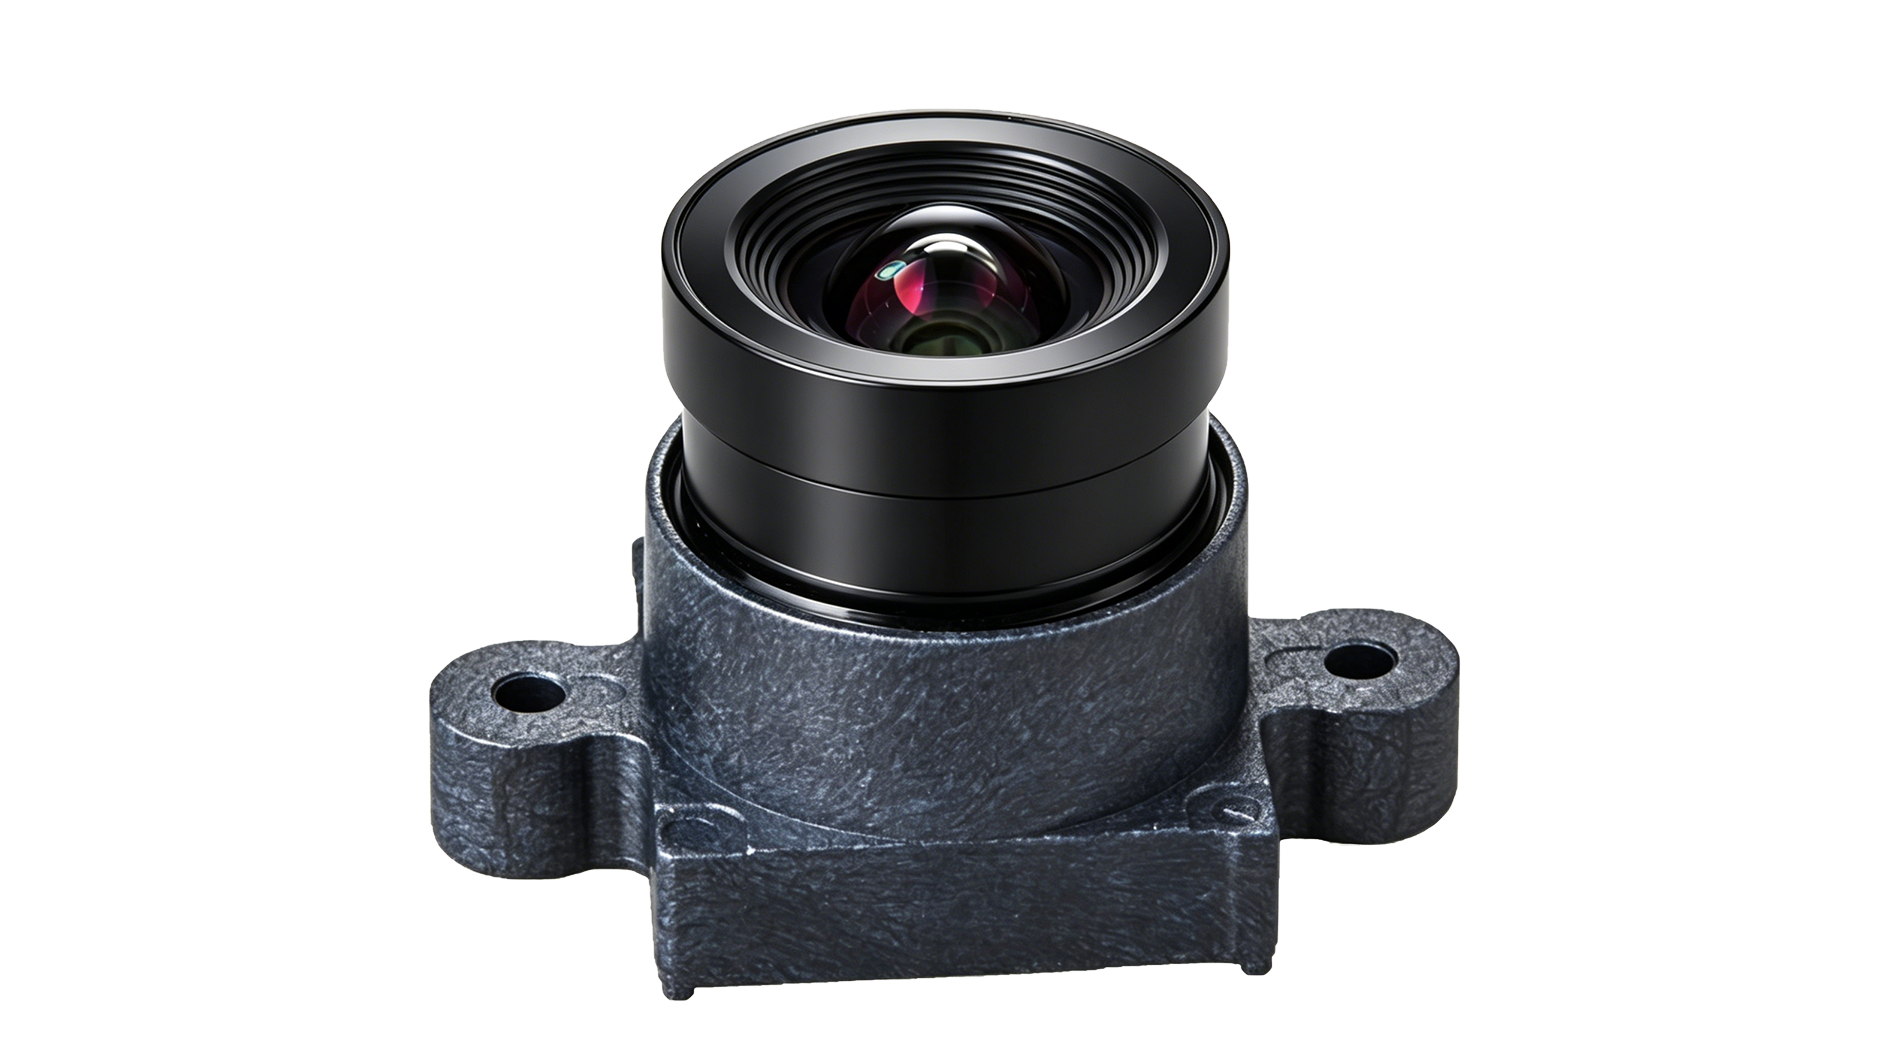
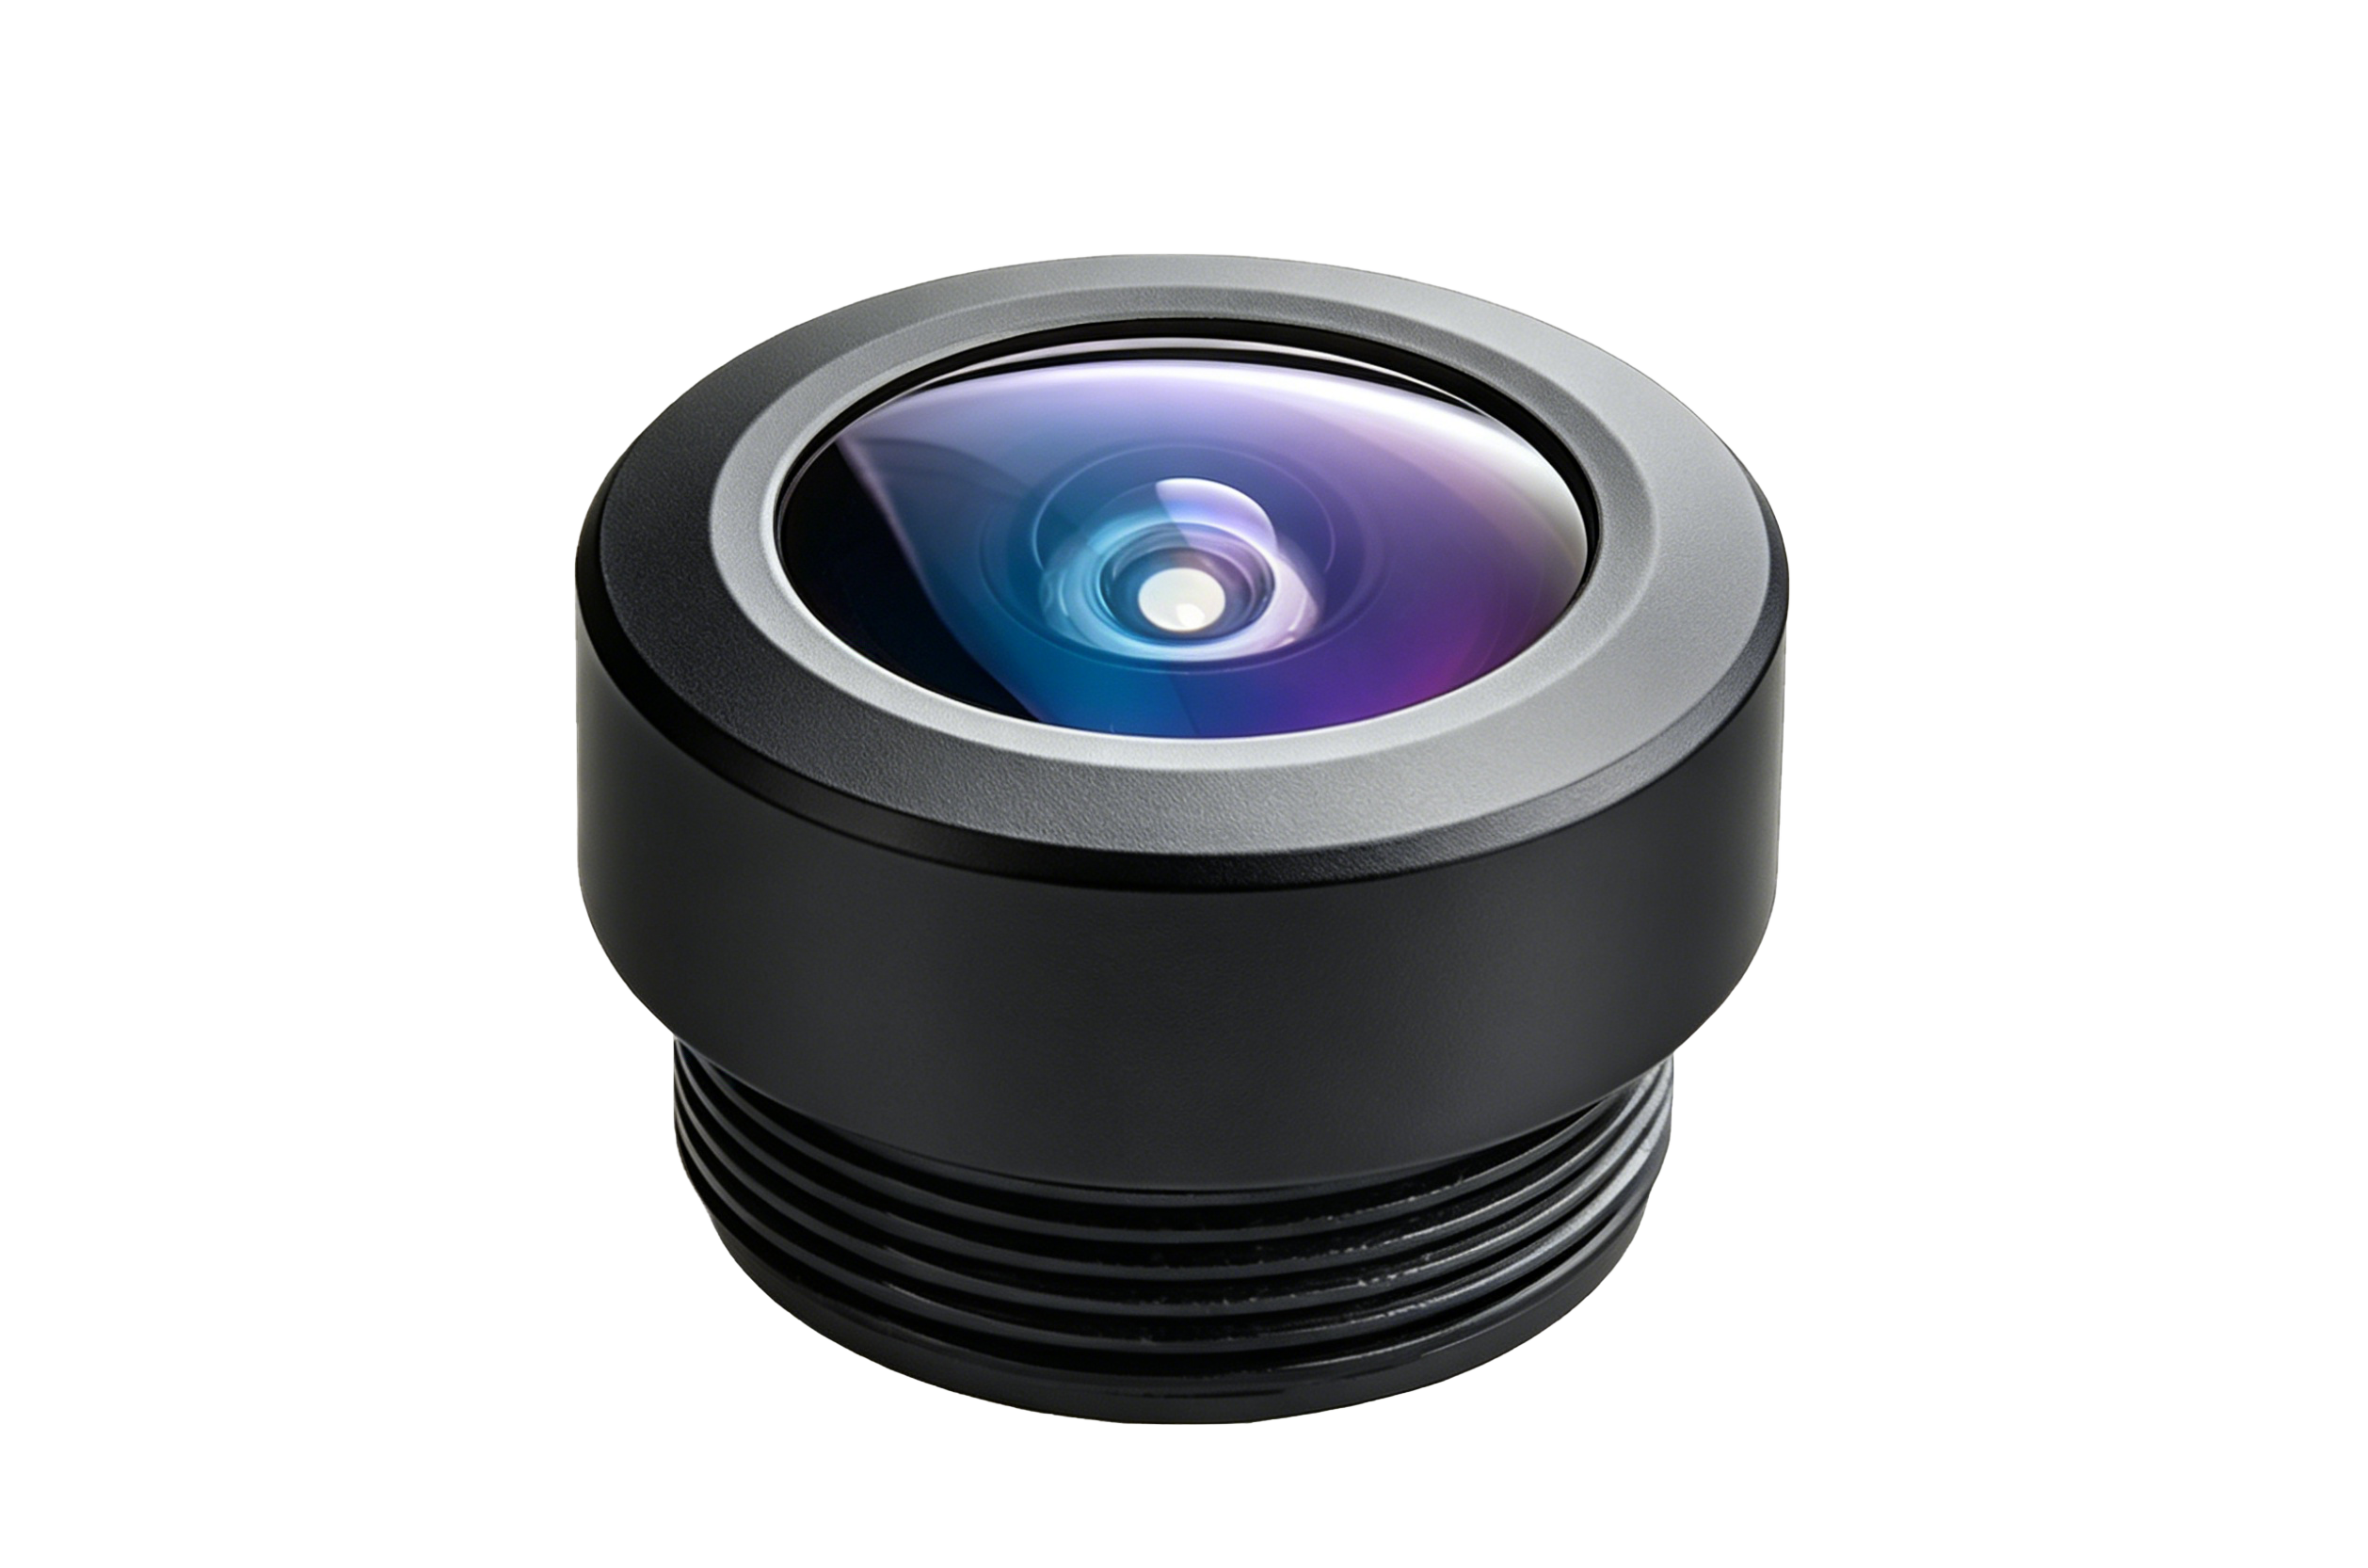
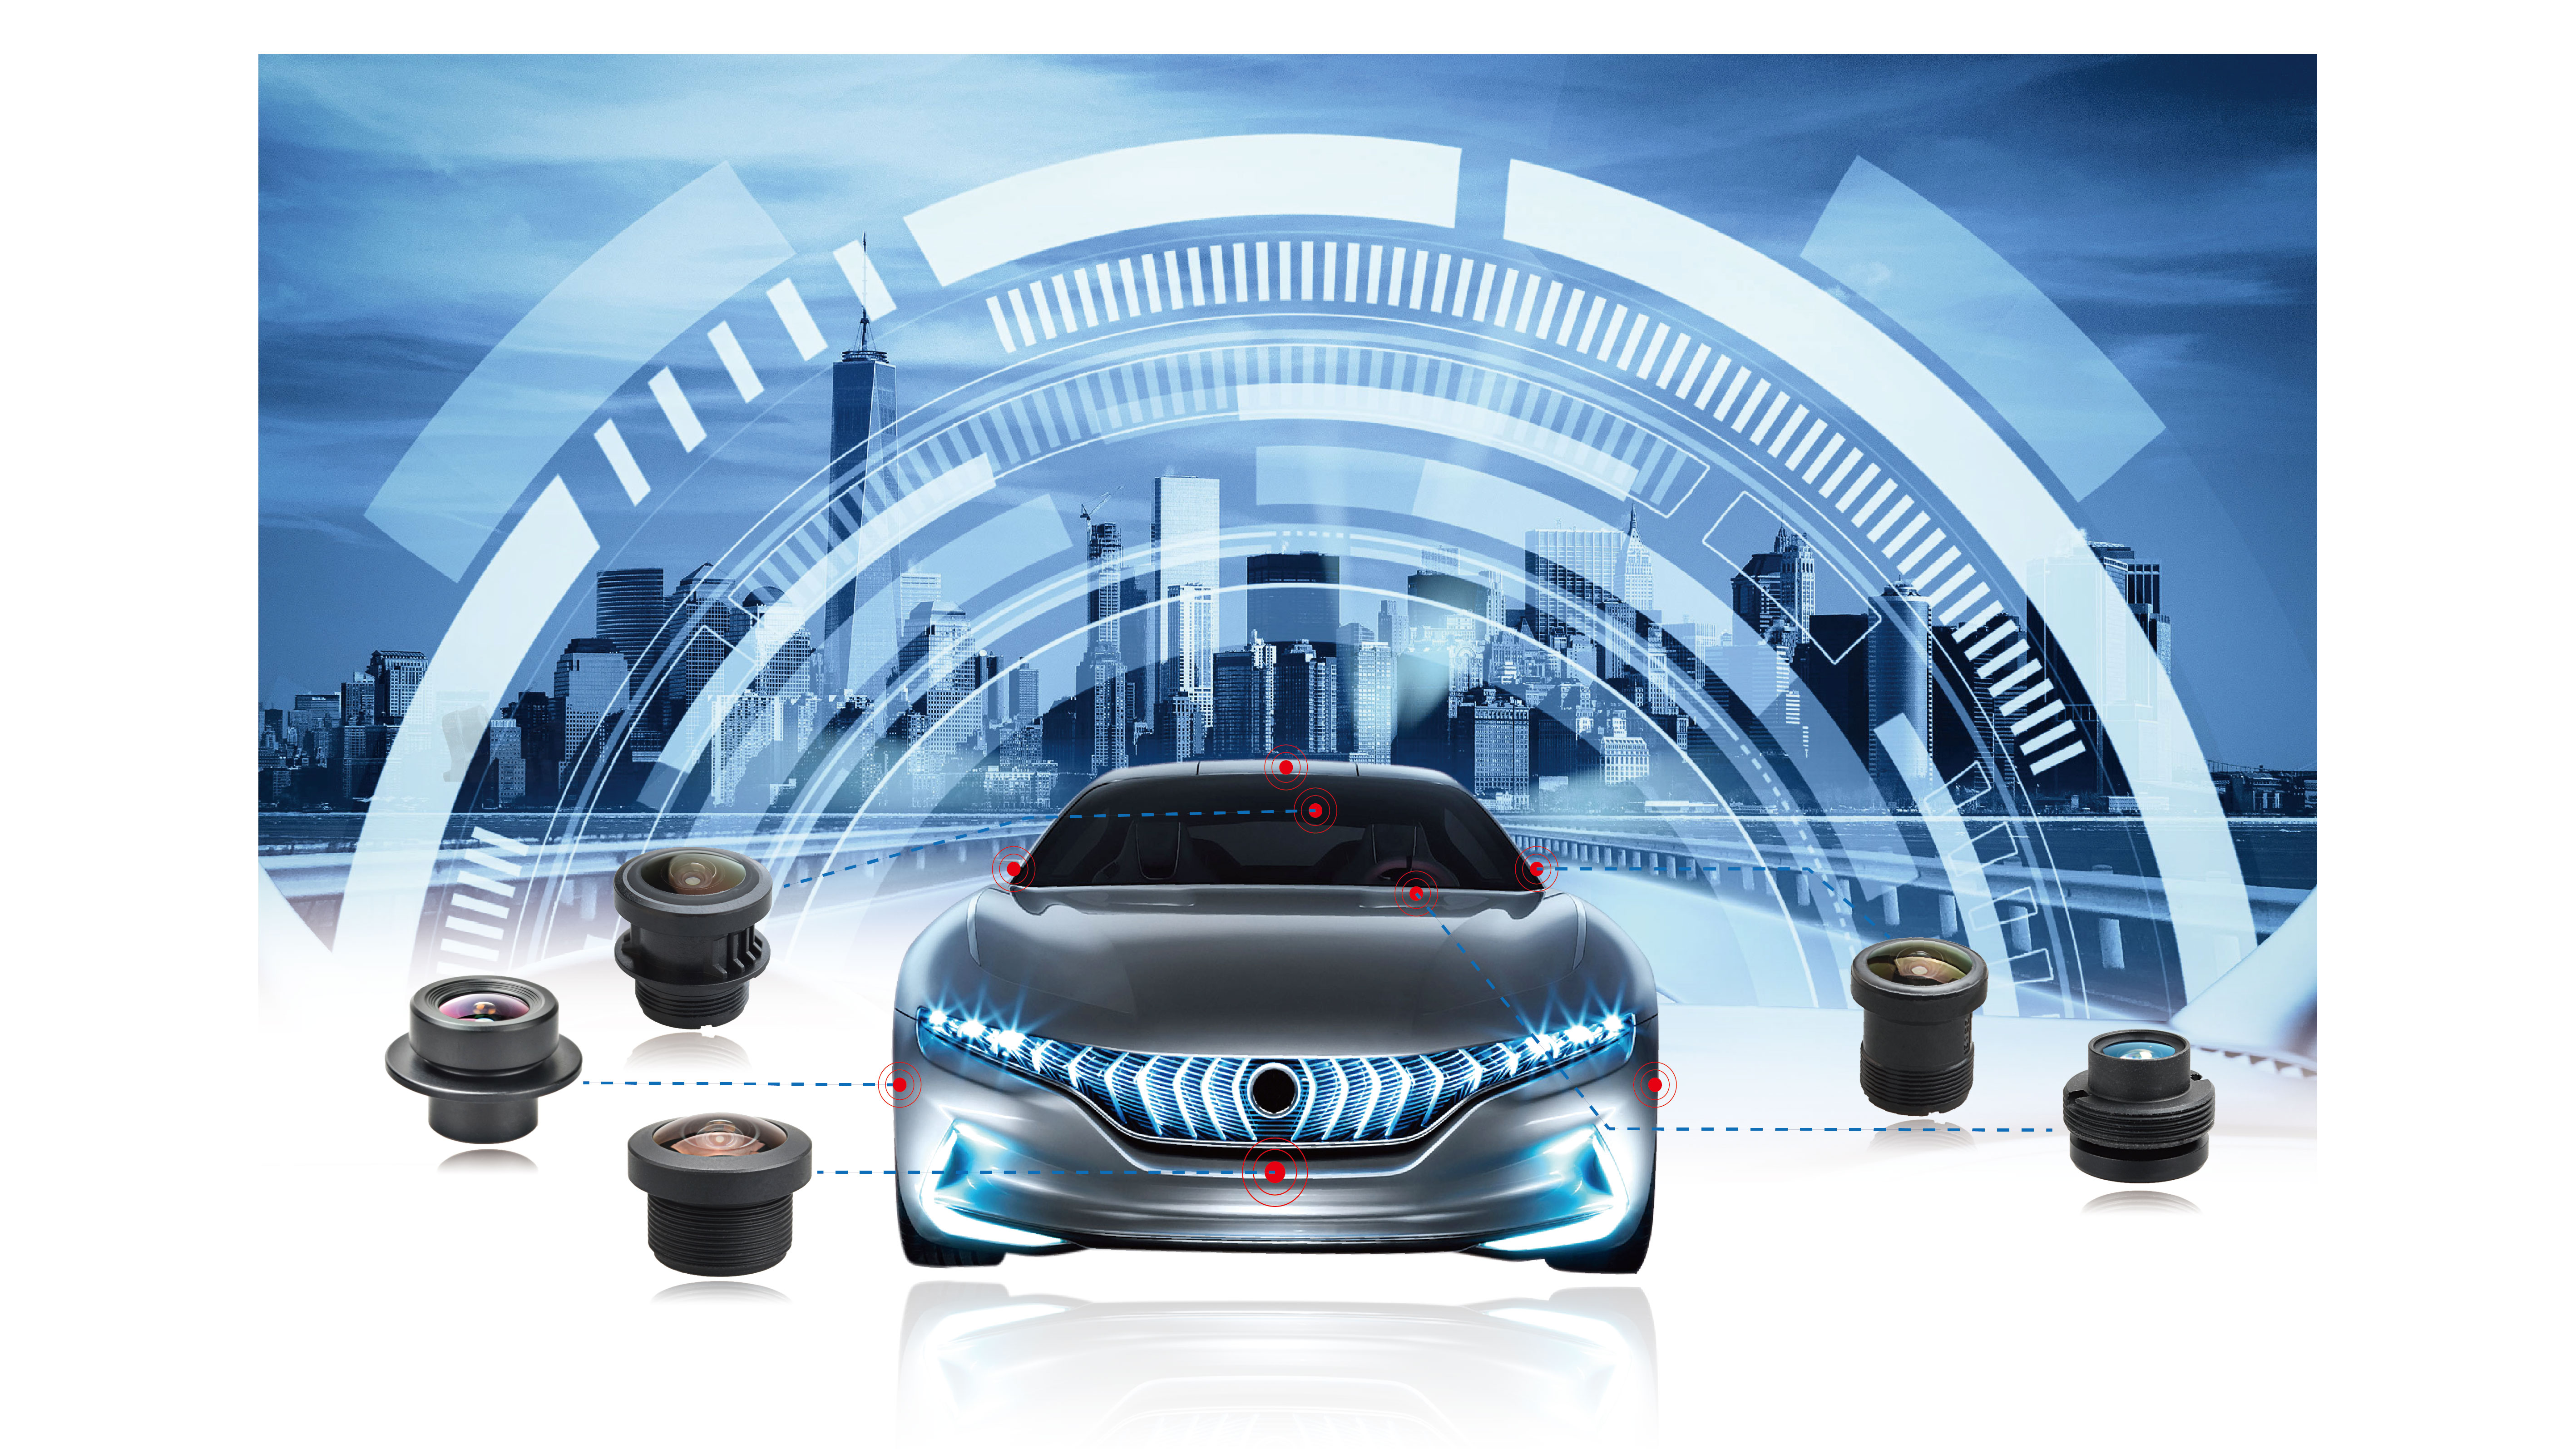
Front main lens: forward capture, path planning, navigation.
Side/leg lenses: obstacle detection, 360° collision avoidance.
Head depth lens: full perception, object recognition, spatial mapping.
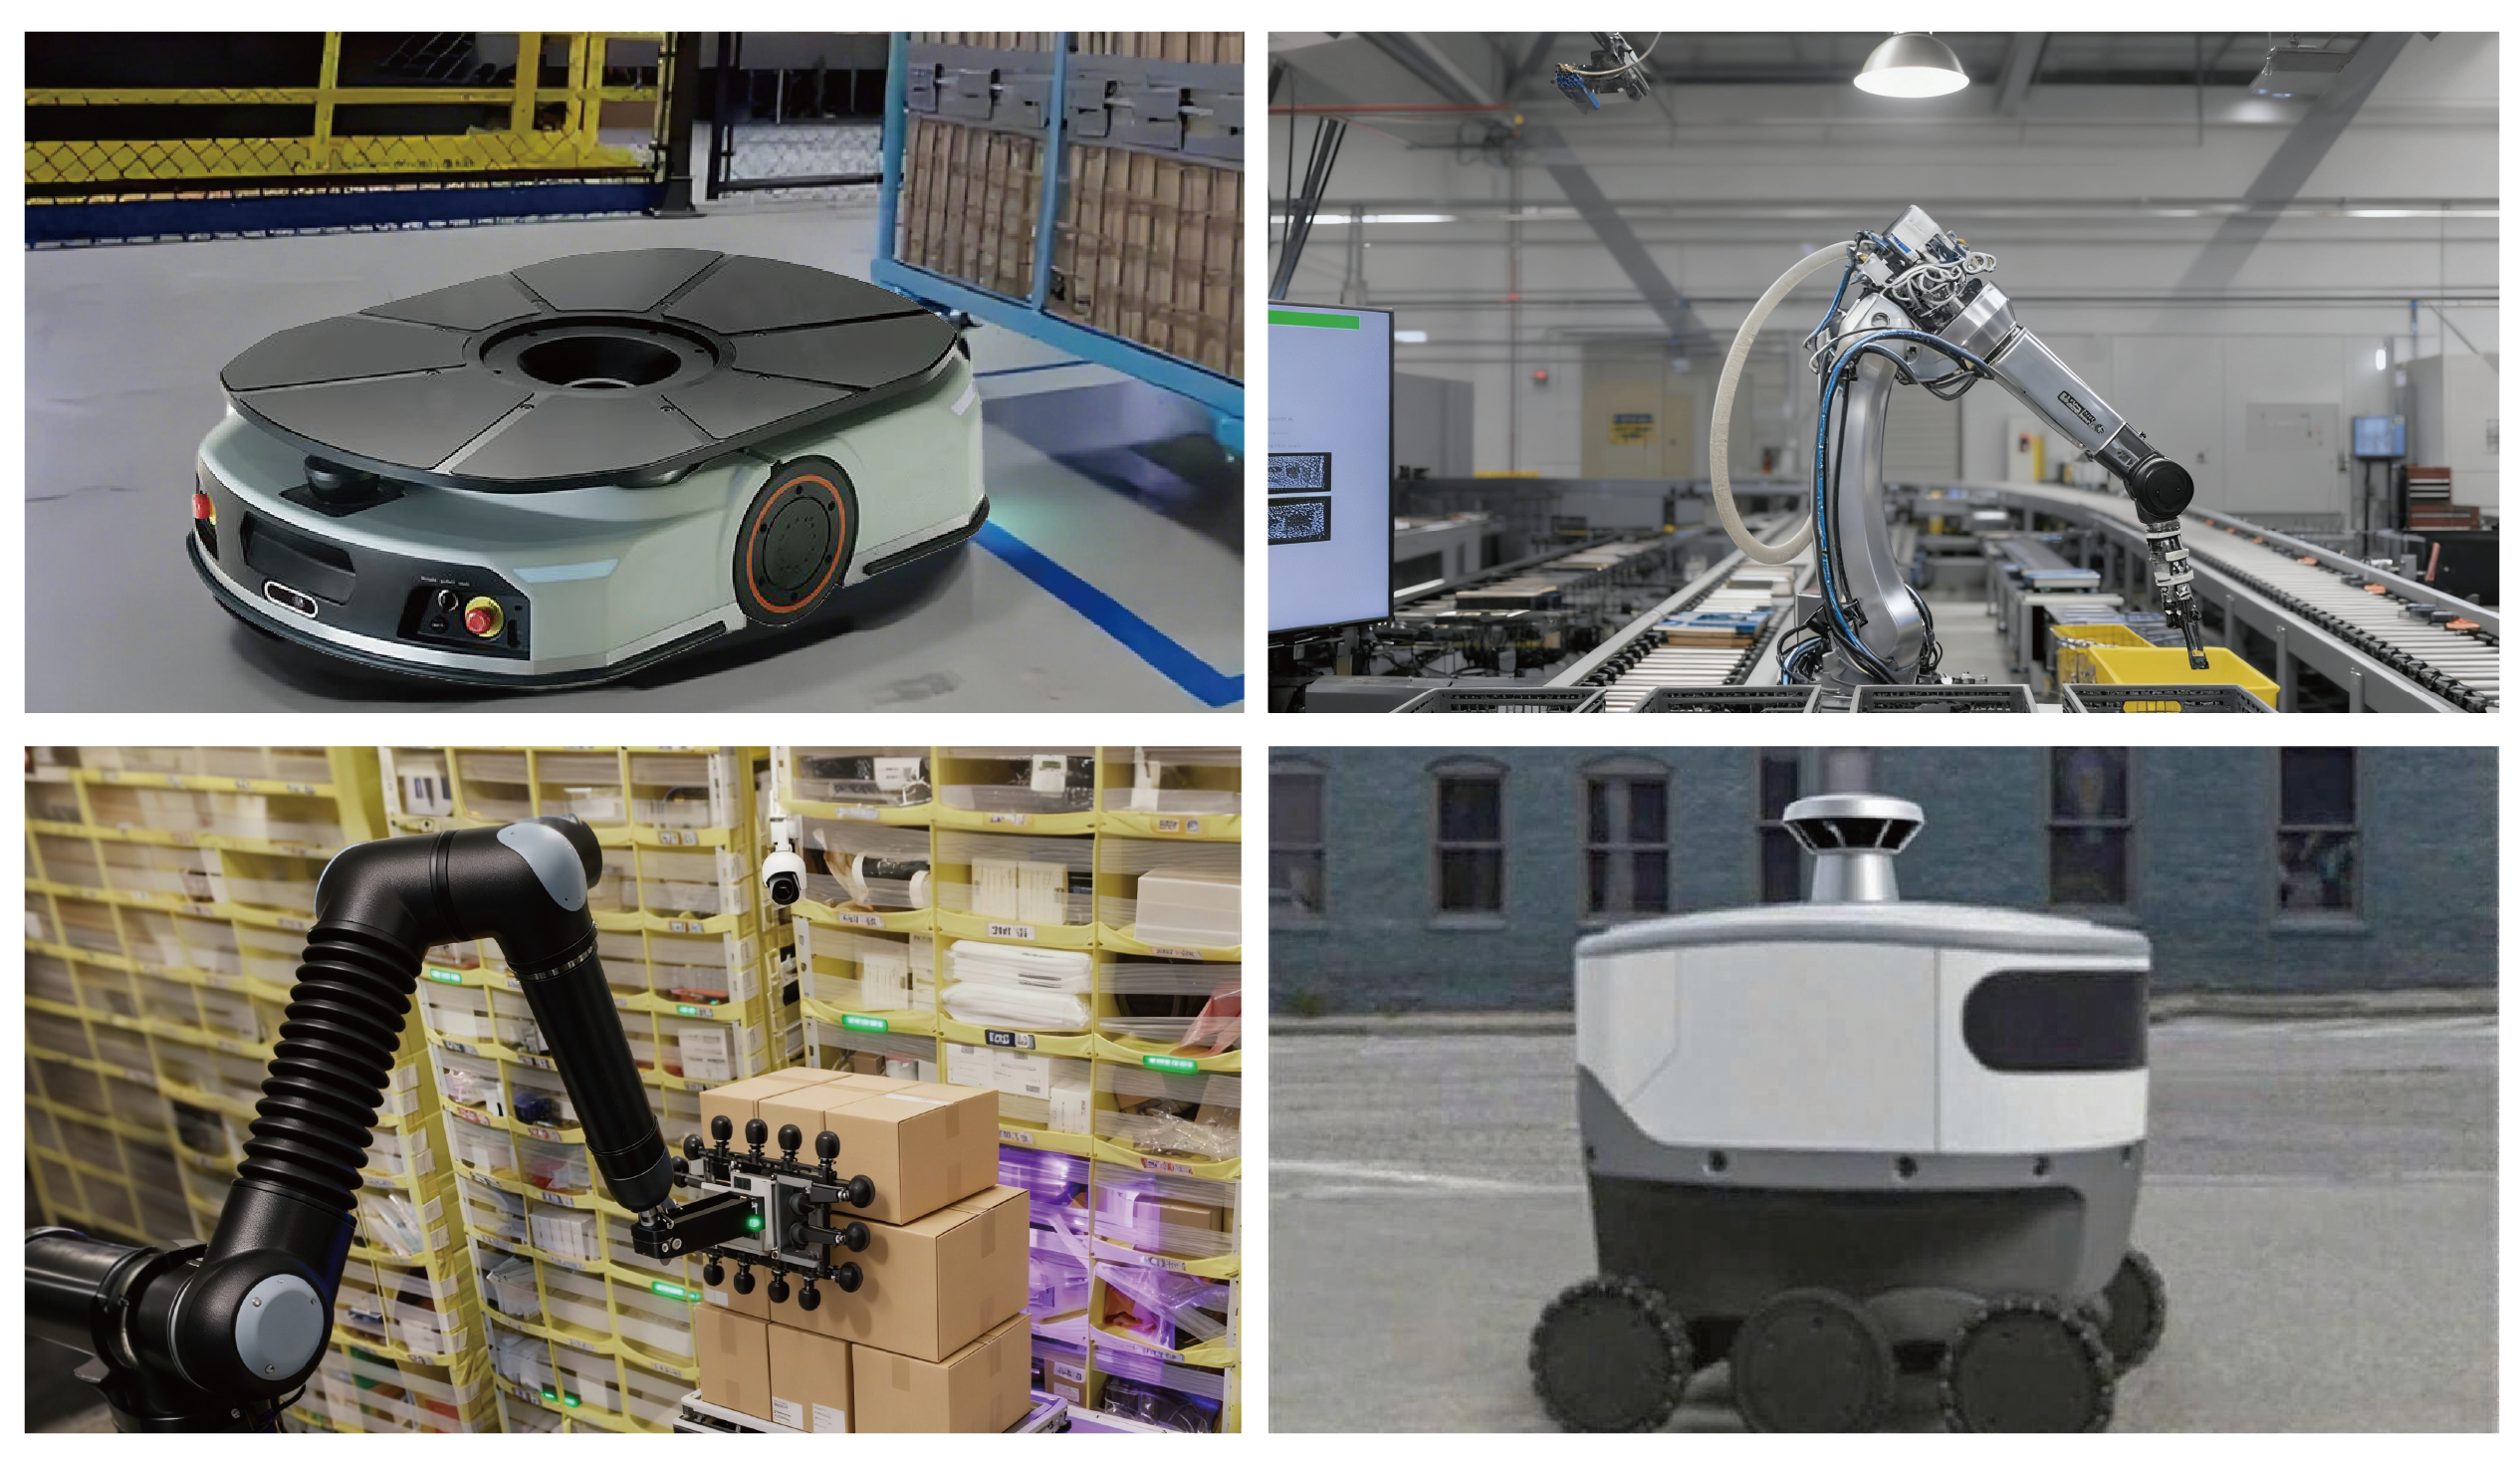
Robotic‑hand lens assembly: precise grasping of small objects.